Robotics Primer
The ideas behind robot perception, localization, and recognition, connected in a progression from intuition to mathematics and implementation.
Find a reading order in the learning guides → Search this field →
Specialized topics in this field
Computer Vision Primer
Control Engineering Primer
Connected & Autonomous Driving
 Computer Vision Primer
September 27, 2026
Lab
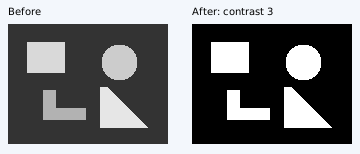
Image brightness and luminance Lab — exposure, gamma and clipping
Compare linear exposure with encoded grey-value adjustments using synthetic images, histograms and gradients.
Hands-on · 2 min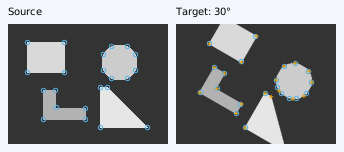 Computer Vision Primer
September 27, 2026
Lab
Feature extraction Lab — compare Harris and Shi–Tomasi
Rotate, resize and change the brightness of synthetic images, then compare detected corners and known reference positions.
Hands-on · 2 min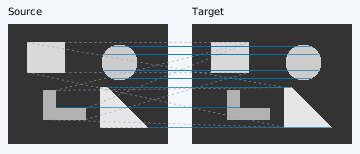 Computer Vision Primer
September 27, 2026
Lab
Feature matching Lab — descriptor filters, geometric inliers and ground truth
Compare image patches, filter proposed correspondences and see why geometric agreement does not guarantee a correct match.
Hands-on · 2 min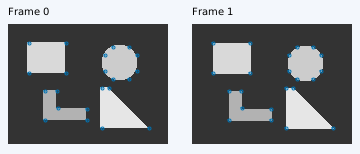 Computer Vision Primer
September 27, 2026
Lab
Optical flow Lab: track motion between two frames
Estimate sparse image motion and compare it with known synthetic motion. Explore brightness changes, occlusion and the aperture problem.
Hands-on · 2 min Control Engineering Primer September 22, 2026 LabMPC Lab — re-solve a curvature sequence within a horizon and steering limits
Change the horizon, weights and steering limit, and compare predicted paths, solver convergence and failure handling in your browser.
Hands-on · 4 min Control Engineering Primer September 22, 2026 LabPath-tracking comparison Lab — run PP, APP, RPP, Stanley and MPC under the same conditions
Run five trackers together on one vehicle, path, initial state and steering limit, and compare cross-track error, smoothness and completion with shared metric definitions.
Hands-on · 3 min Control Engineering Primer September 21, 2026 LabAdaptive Pure Pursuit Lab — scale lookahead with speed
Compare speed-scaled lookahead with PP, including acceleration and minimum/maximum bounds.
Hands-on · 3 min Control Engineering Primer September 21, 2026 LabPure Pursuit Lab — compare fixed-lookahead path tracking
Change fixed lookahead and inspect tracking error, steering and targets on a shared vehicle model.
Hands-on · 3 min Control Engineering Primer September 21, 2026 LabRegulated Pure Pursuit Lab — speed through curves and near the goal
Separate lookahead from speed regulation and compare curvature limits, speed floors, final approach and actual vehicle speed.
Hands-on · 4 min Control Engineering Primer September 21, 2026 LabStanley Lab — steering from front-axle cross-track and heading error
Separate front and rear axle errors and compare gain, speed and steering constraints in your browser.
Hands-on · 3 min Computer Vision Primer
September 13, 2026
Monocular Depth Estimation — From Relative Order to Metric Distance
A primer on monocular depth: relative versus metric depth, scale ambiguity, evaluation protocols, and failure conditions.
Learning guide · 3 min Computer Vision Primer
September 13, 2026
Neural 3D — Novel-View Synthesis and Separate Visual/Geometric Evaluation
A primer on neural scene representations, novel-view synthesis, held-out views, and separate visual and geometric evaluation.
Learning guide · 2 min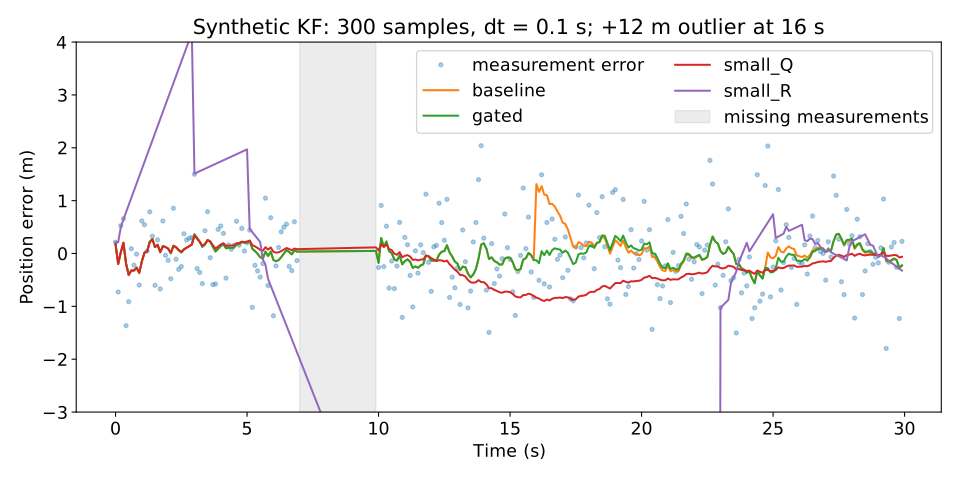 Control Engineering Primer
September 8, 2026
Lab
Run a Kalman filter in Python: noise, missing data and outliers
Compare Q, R and outlier gating on one synthetic trajectory using estimation error and rejected observations.
Hands-on · 3 min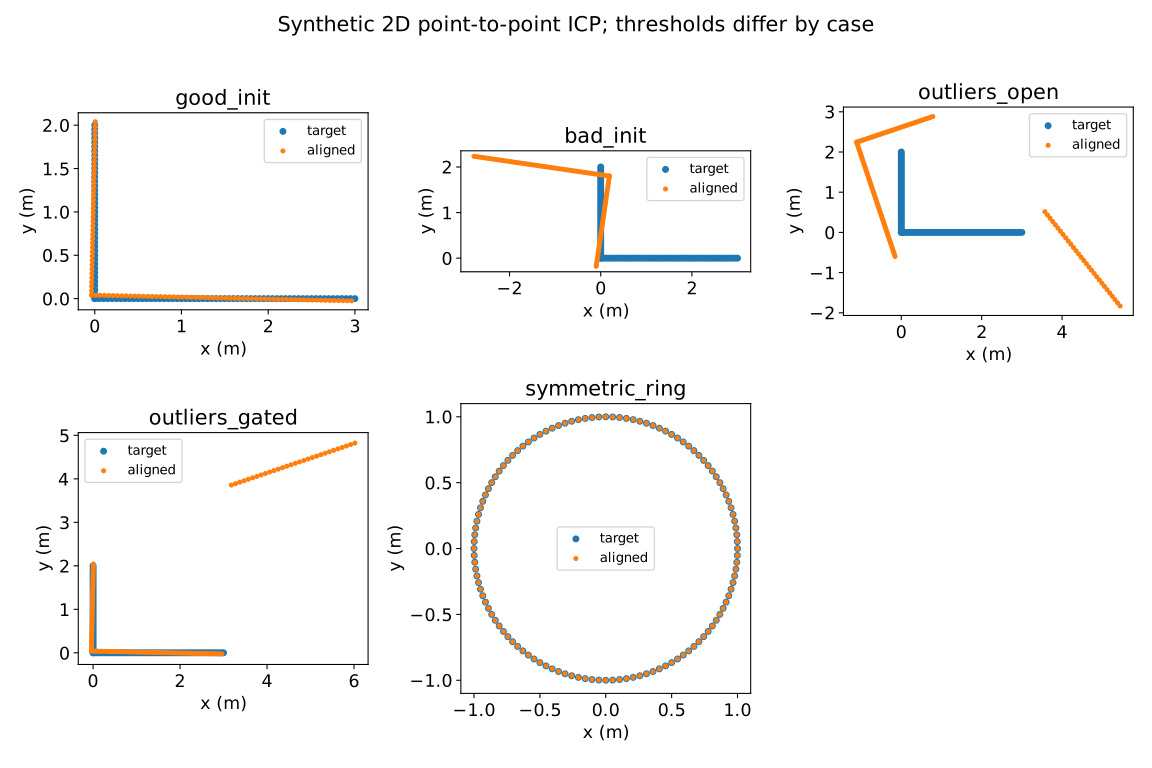 Robotics Primer
September 8, 2026
Lab
Why ICP fails: initialization, outliers and symmetric geometry
Run 2D registration and distinguish residuals, correspondence coverage and true pose error.
Hands-on · 3 min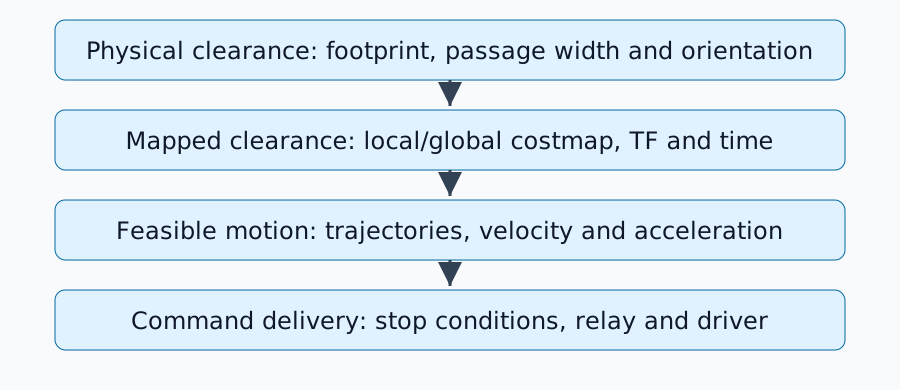 Robotics Primer
September 8, 2026
Lab
Nav2 has a path but will not move: a diagnostic workflow
Inspect geometry, costmaps, control feasibility and command delivery to explain a stopped robot.
Hands-on · 4 min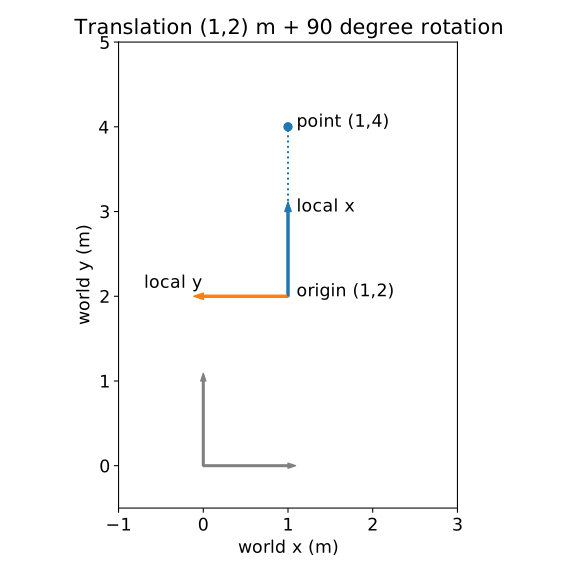 Robotics Primer
September 8, 2026
Lab
Robot coordinate transforms: matrices, quaternions and TF
Use a numeric example to connect rotation, translation, inverse transforms, quaternions and ROS frames.
Fundamentals · 3 min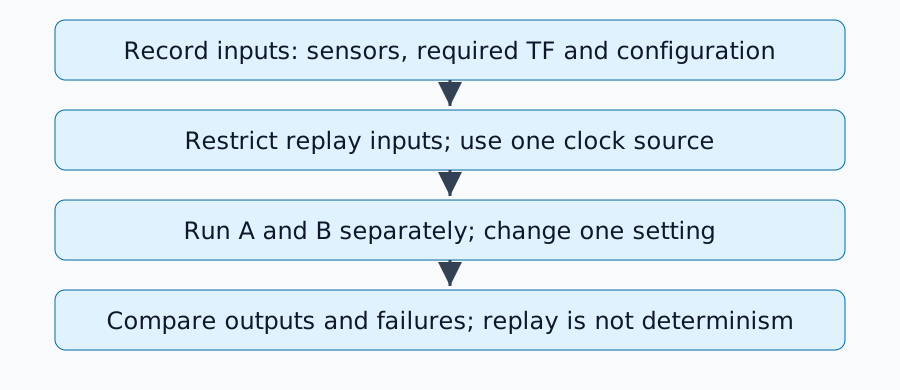 Robotics Primer
September 8, 2026
Lab
Reproduce robot failures with rosbag2: inputs, TF and time
Build controlled replay comparisons and diagnose duplicate TF publishers and mixed time sources.
Hands-on · 5 min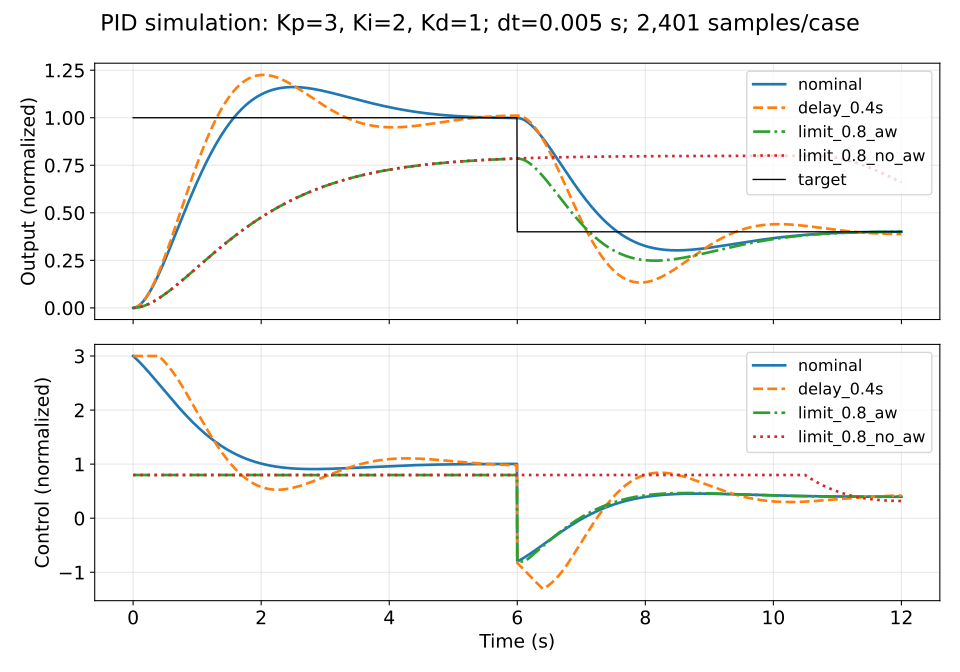 Control Engineering Primer
September 7, 2026
Lab
Experiment with PID in Python — gains, delay and saturation
Reproduce how measurement delay, actuator limits and integral windup change PID tracking on the same second-order model.
Hands-on · 2 min Computer Vision Primer
September 7, 2026
Feature Tracking Primer — How to Avoid Losing the Same Point Between Frames
Feature tracking is the process of matching the same physical point across frames in a video sequence. This article organizes template tracking, Lucas–Kanade optical flow, descriptor matching, RANSAC, outlier rejection, and Kalman prediction with equations and implementation steps, and explains the conditions under which Visual Odometry and SLAM break down, along with mitigations.
Fundamentals · 6 min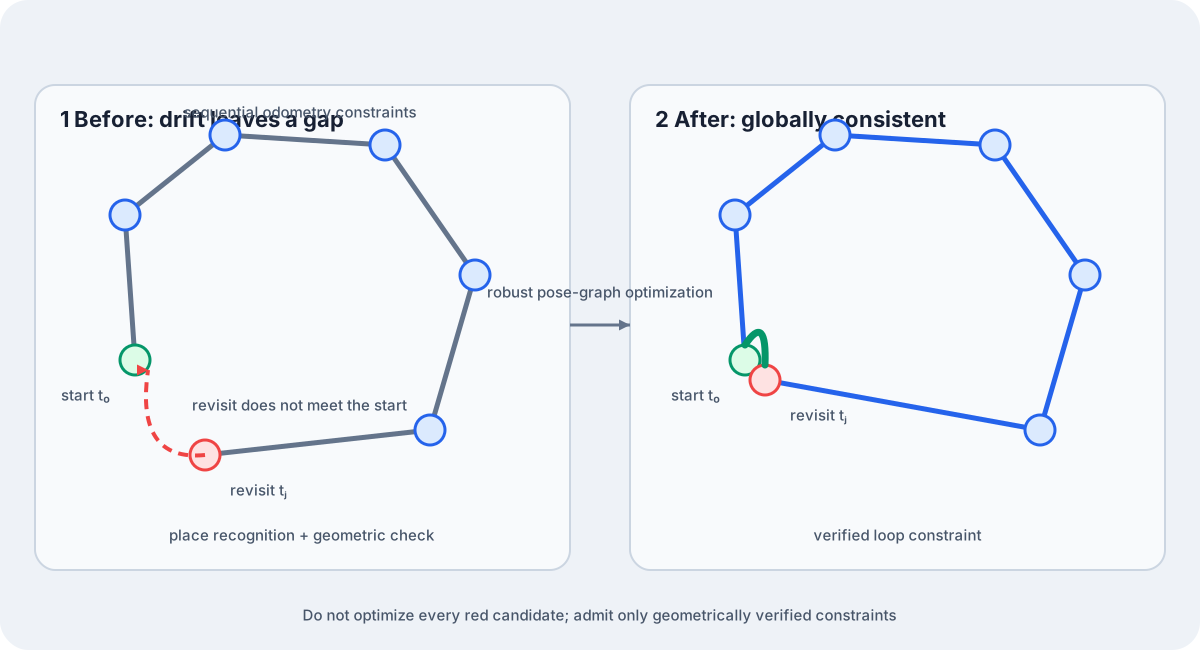 Computer Vision Primer
September 7, 2026
Loop Closure Primer — Fixing a SLAM System's Drift All at Once, Around a Loop
Loop closure is the process of recognizing that a robot has returned to a previously visited place, and distributing the accumulated self-localization error across the whole map. This article systematically explains place recognition, image retrieval, geometric verification, pose-graph optimization, defenses against false positives, and current SLAM implementations and research.
Fundamentals · 5 min Computer Vision Primer
September 7, 2026
Optical Flow Primer — Reading Velocity and Structure from Image Motion
Optical Flow is a vector field describing which direction each pixel in a sequence of images has moved. This article works through the brightness-constancy constraint, Lucas–Kanade and Horn–Schunck, pyramids, dense flow versus sparse feature tracking, learning-based methods such as RAFT, and camera motion, dynamic objects, and evaluation methodology, with the underlying math.
Fundamentals · 5 min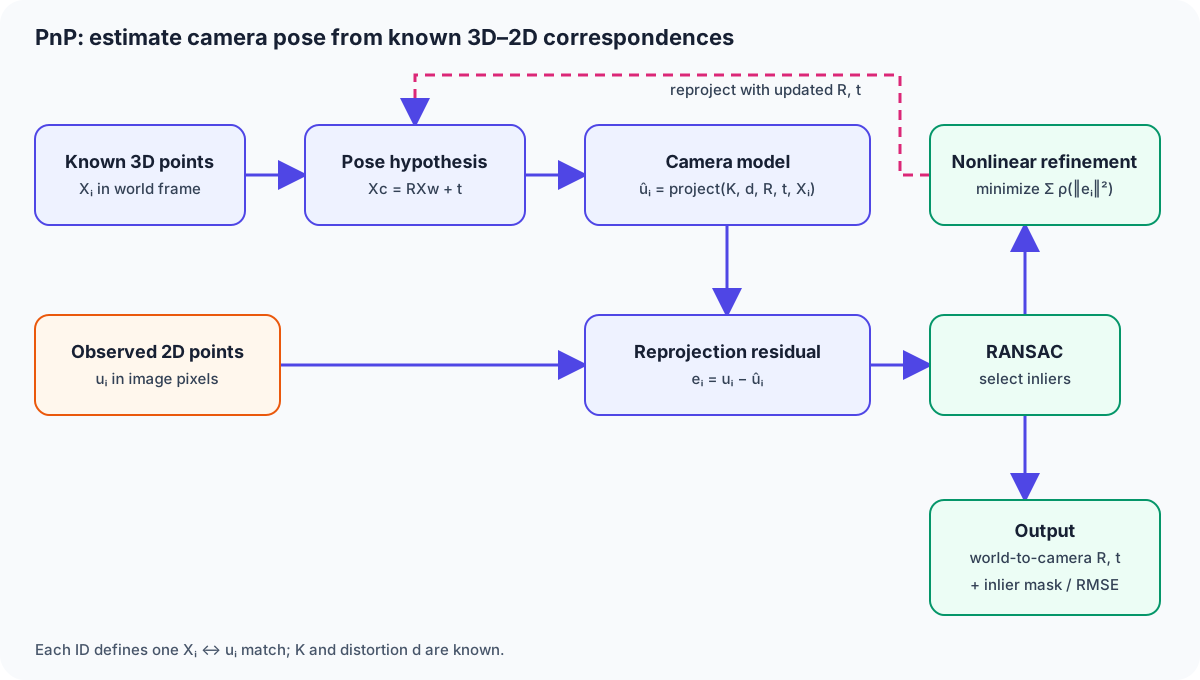 Computer Vision Primer
September 7, 2026
PnP Primer — Recovering Camera Pose from Nothing but 3D Points and an Image
Perspective-n-Point (PnP) is the geometric problem of estimating a camera's position and orientation from known 3D points and their corresponding image points. This article works through the projection equation, P3P/AP3P, EPnP, iterative optimization, RANSAC, planar degeneracy, and how PnP is used in Visual SLAM, AR, and surveying, with the math and an implementation checklist.
Fundamentals · 8 min Robotics Primer
September 7, 2026
Hydraulic Systems Primer — From Pascal's Principle to Force Control in Robots
Why can a small input move a hydraulic excavator's massive arm? This article treats the pump, control valves, cylinder, hydraulic fluid, sensors, and controller as a single closed loop, covering the pressure/flow/efficiency equations, current technology in construction and agricultural machinery, and electro-hydraulic conversion and current research, with diagrams.
Fundamentals · 8 min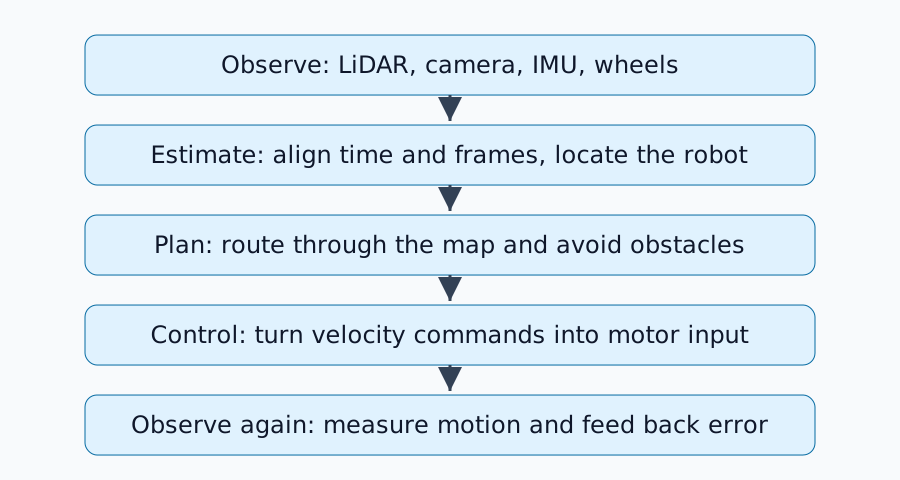 Robotics Primer
September 7, 2026
Indoor robotics roadmap — from sensors to motion control
Connect sensing, localization, mapping, planning and control, then choose a reading path for the system you want to build.
Learning guide · 2 min Robotics Primer
September 7, 2026
LiDAR-SLAM Primer — Knowing "Where Am I" from Laser Point Clouds
A camera infers distance indirectly from patterns of reflected light; a LiDAR measures distance directly from the time of flight of a laser pulse. LiDAR-SLAM is the technology built on registering the point clouds this active ranging sensor returns. This article works systematically from the two pillars of scan matching, ICP and NDT, through LOAM's feature design, Loop Closure and Graph SLAM, up to the lineage of landmark algorithms — LeGO-LOAM, Cartographer, LIO-SAM, FAST-LIO2.
Fundamentals · 20 min Robotics Primer
September 7, 2026
VIO/LIO Primer — Combining an IMU with a Camera or LiDAR for Self-Localization
A camera alone, or a LiDAR alone, breaks down in certain situations. Combining either sensor with an IMU (accelerometer + gyroscope) covers for that weakness -- this is what VIO (Visual-Inertial Odometry) and LIO (LiDAR-Inertial Odometry) do. Starting from why an IMU alone cannot recover position, this article works through the two design philosophies -- Filter-based and Optimization-based -- and the landmark algorithms from ROVIO, OKVIS, VINS-Mono, and OpenVINS through LIO-SAM and FAST-LIO2.
Fundamentals · 16 min Computer Vision Primer
September 7, 2026
Visual-SLAM Primer — How a Camera Learns "Where Am I"
With no GPS and no map, a robot can still find its own position and build a map of its surroundings from camera images alone. From feature tracking through epipolar geometry, the difference between Visual Odometry and SLAM, the lineage of landmark algorithms from ORB-SLAM to LSD-SLAM and DSO, and Bundle Adjustment, a systematic ground-up tour of how Visual-SLAM actually works.
Fundamentals · 18 min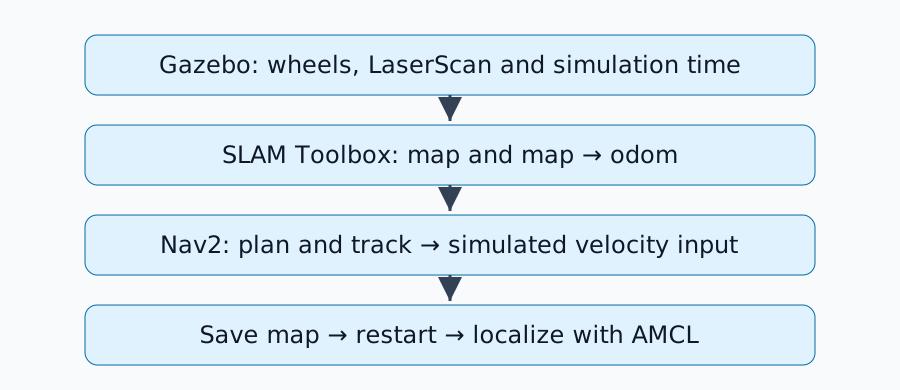 Robotics Primer
September 7, 2026
Lab
From mapping to navigation in ROS 2 — a minimal Jazzy and Nav2 procedure
Use the Jazzy simulation to check mapping, map saving, reloading and goal navigation as separate steps.
Hands-on · 4 min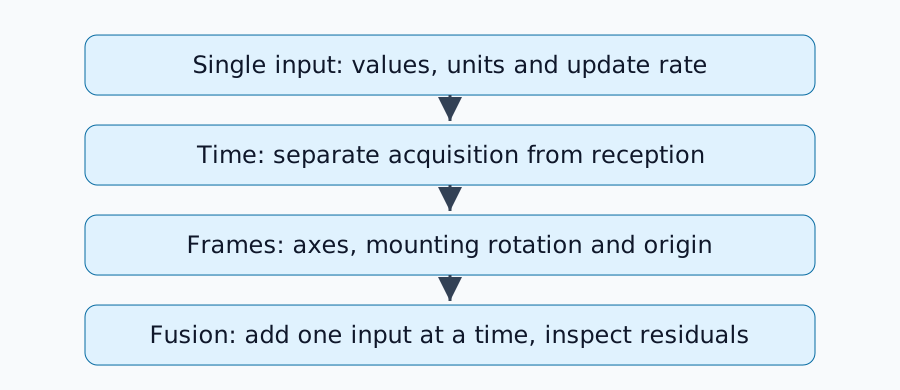 Robotics Primer
September 7, 2026
Lab
Why sensor fusion fails — timing, frames and extrinsic calibration
Diagnose fusion failures through timestamps, coordinate frames, mounting geometry and covariance.
Fundamentals · 4 min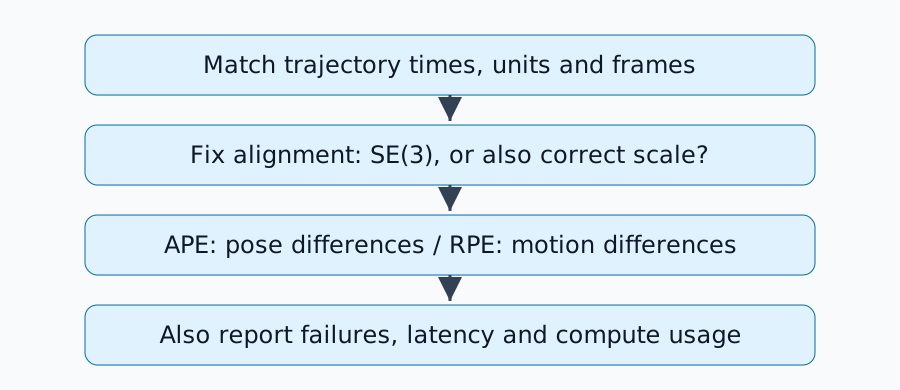 Robotics Primer
September 7, 2026
Lab
How to evaluate SLAM — ATE, RPE, runtime and failures
Use synthetic trajectories to distinguish absolute and relative errors, then define matching, alignment and failure reporting for an evaluation.
Hands-on · 3 min
Robotics Primer
September 6, 2026
Sensor Fusion Primer — Building One World Model From Many Sensors
A camera is strong on meaning, a LiDAR is strong on geometry, an IMU is strong on motion — and each has its own blind spot. From the probabilistic and optimization-based math that fuses them (Kalman Filters, Factor Graphs) to concrete pairings like VIO (Camera×IMU), LIO (LiDAR×IMU), and BEV Fusion (Camera×LiDAR), a systematic tour of how Sensor Fusion turns several sensors into a single world model.
Fundamentals · 15 min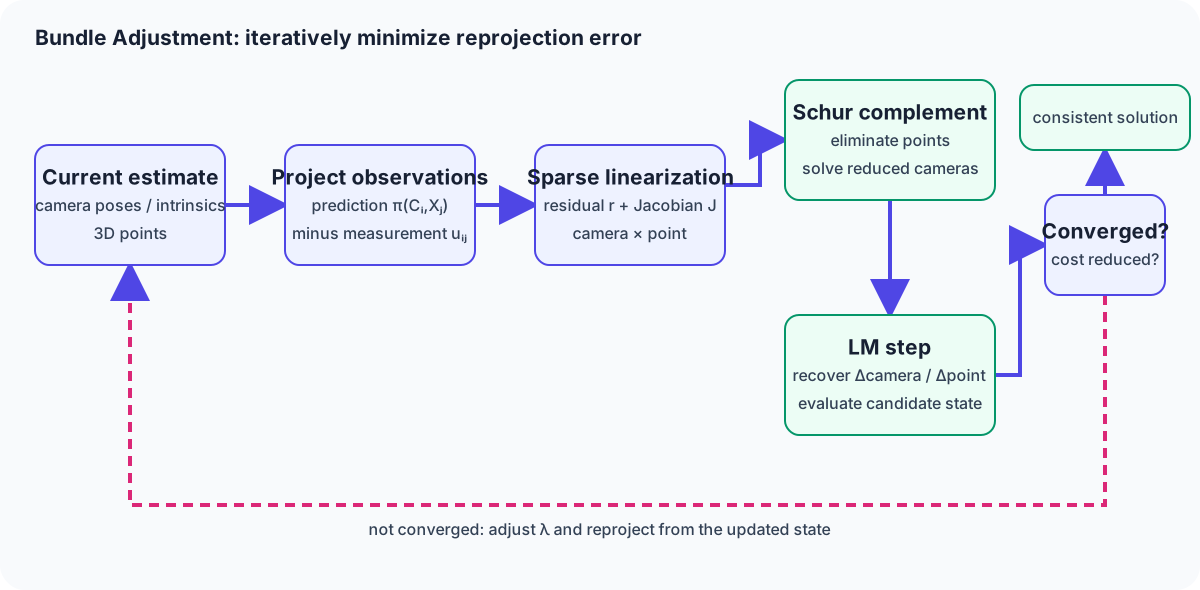 Computer Vision Primer
September 4, 2026
Bundle Adjustment Primer — the Nonlinear Least Squares That Polish Camera Poses and 3D Points Together
Bundle Adjustment is a nonlinear least-squares problem that moves many camera poses and 3D points at once to minimize the reprojection error across all observations. This article systematically covers why the Jacobian is sparse, why the Schur complement makes large-scale problems solvable, the role of the Levenberg-Marquardt method, gauge freedom, and the relationship to Pose Graph optimization and SfM, with equations and diagrams.
Fundamentals · 11 min Computer Vision Primer September 4, 2026Camera Calibration Primer — Recovering Lens Distortion and Intrinsic Parameters
Camera calibration is the process of recovering the intrinsic parameters and lens distortion needed to map pixel coordinates onto 3D space. From revisiting the pinhole model, through radial and tangential distortion models, Zhang's planar-pattern method, reprojection-error optimization, to what breaks downstream in Visual SLAM and VO when calibration drifts — a systematic walkthrough with equations and diagrams.
Fundamentals · 9 min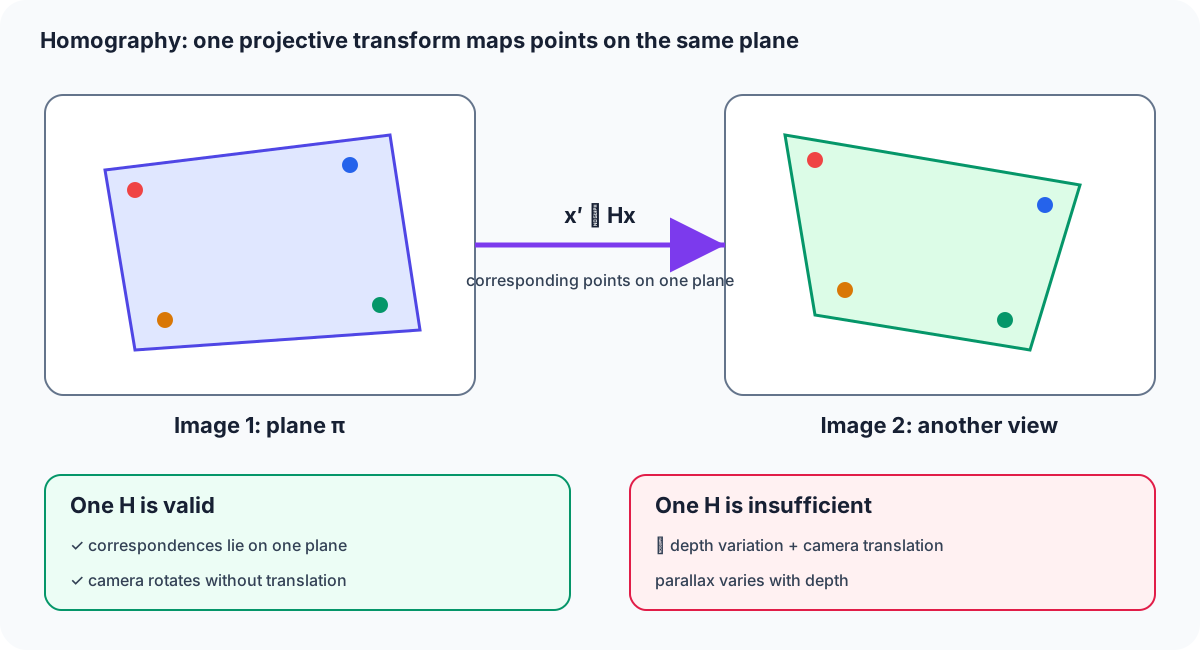 Computer Vision Primer
September 4, 2026
Homography Primer — Describing Planar Correspondence With a Single 3x3 Matrix
A homography is the relation that ties together points on the same plane, or the view of a purely rotating camera, using a single 3x3 projective transform. This article covers DLT-based estimation, robustification with RANSAC, decomposition into rotation, translation, and plane normal, and when to use it versus epipolar geometry, alongside applications like image stitching and AR plane tracking, with equations and diagrams.
Fundamentals · 8 min Computer Vision Primer September 4, 2026Multi-View Stereo Primer — Filling a Sparse Point Cloud Into Dense 3D Shape
Multi-View Stereo (MVS) recovers dense 3D shape from many images using known camera poses. This article systematically covers the core principle of photo-consistency, the two classical approaches of Plane-Sweep and Patch-based (PMVS), deep-learning-based methods epitomized by MVSNet, and meshing via depth-map fusion, alongside the relationship to stereo and depth cameras, with equations and diagrams.
Fundamentals · 11 min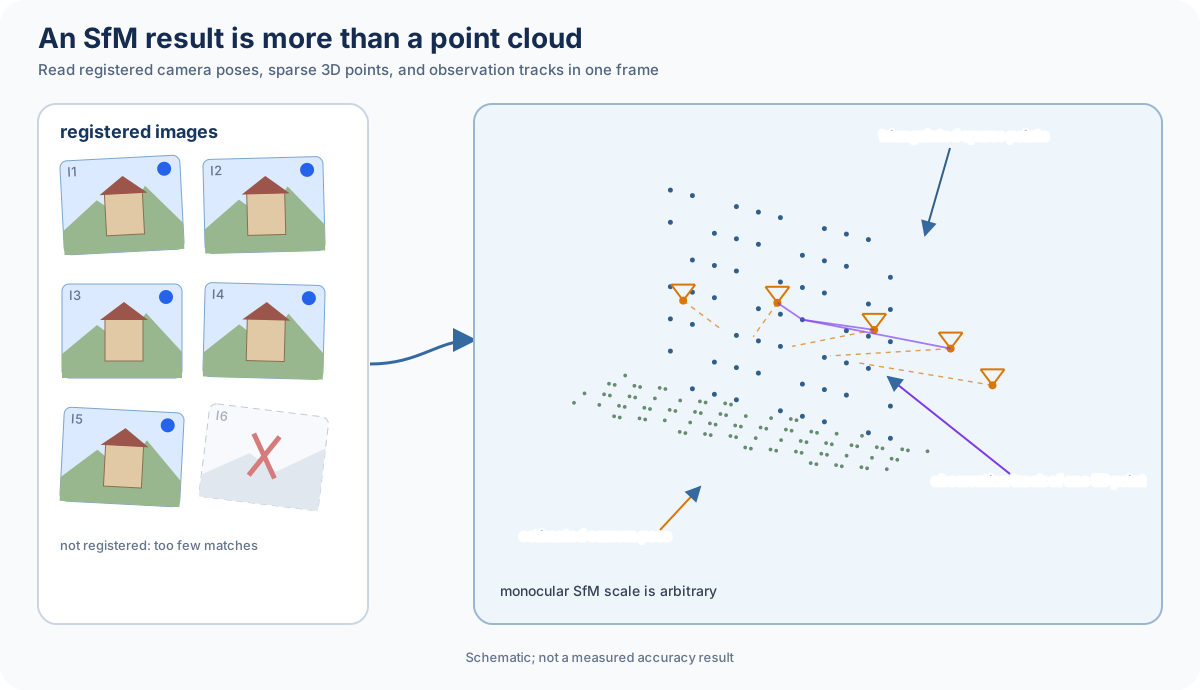 Computer Vision Primer
September 4, 2026
Structure from Motion Primer — Recovering 3D and Camera Positions Together From an Unordered Set of Photos
Structure from Motion (SfM) recovers both a scene's 3D structure and every camera pose simultaneously from a set of photos whose order and shooting positions are unknown. This article systematically covers feature matching, geometric verification, the two reconstruction strategies of Incremental and Global SfM, triangulation, the relationship to Bundle Adjustment, and the difference from Visual-SLAM, alongside current implementations like COLMAP.
Fundamentals · 10 min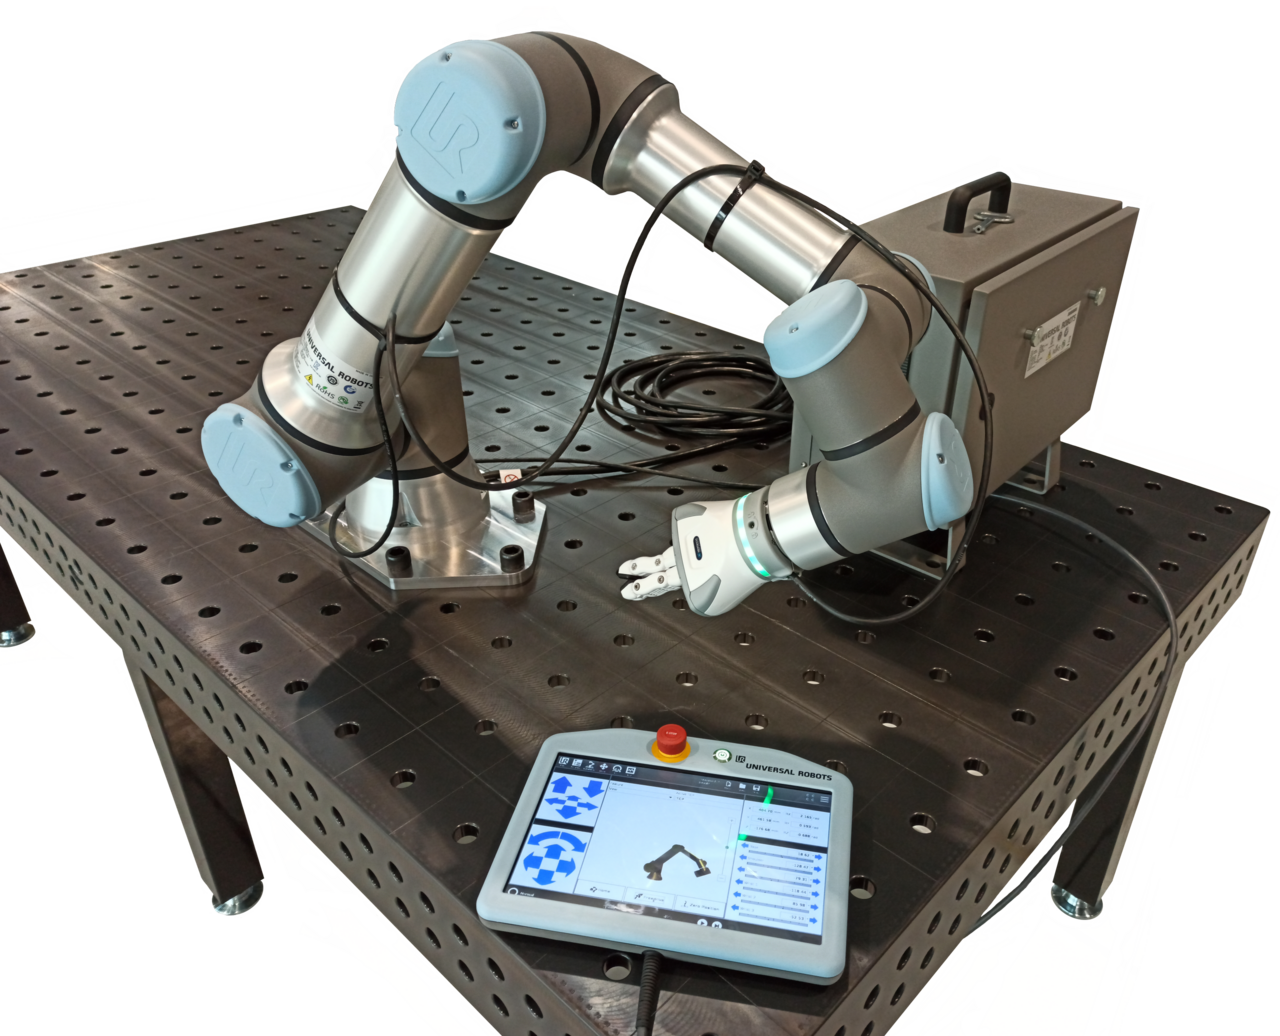 Robotics Primer
September 4, 2026
Robot Arm Kinematics Primer — Forward Kinematics, Inverse Kinematics, and the Jacobian
Forward kinematics finds the hand's position and orientation from the joint angles; inverse kinematics solves the reverse problem; and the Jacobian bridges the two through "velocity." From building coordinate transforms with DH parameters, through analytic IK, numerical IK (Damped Least Squares), singularities, and redundant degrees of freedom — a ground-up, systematic account of the kinematics that governs how a robot arm moves.
Fundamentals · 13 min Robotics Primer
September 4, 2026
Force Control and Impedance Control Primer — Building a Robot That Can Touch
Starting from what actually happens the instant a position-controlled robot arm touches a rigid object — and why that makes assembly, polishing, and human-contact tasks impossible — this article works through impedance control, which links force and displacement via a virtual spring, damper, and mass; admittance control, which reverses that causality; and hybrid position/force control, which separates position and force by spatial direction, building the ideas up from equations and diagrams.
Fundamentals · 14 min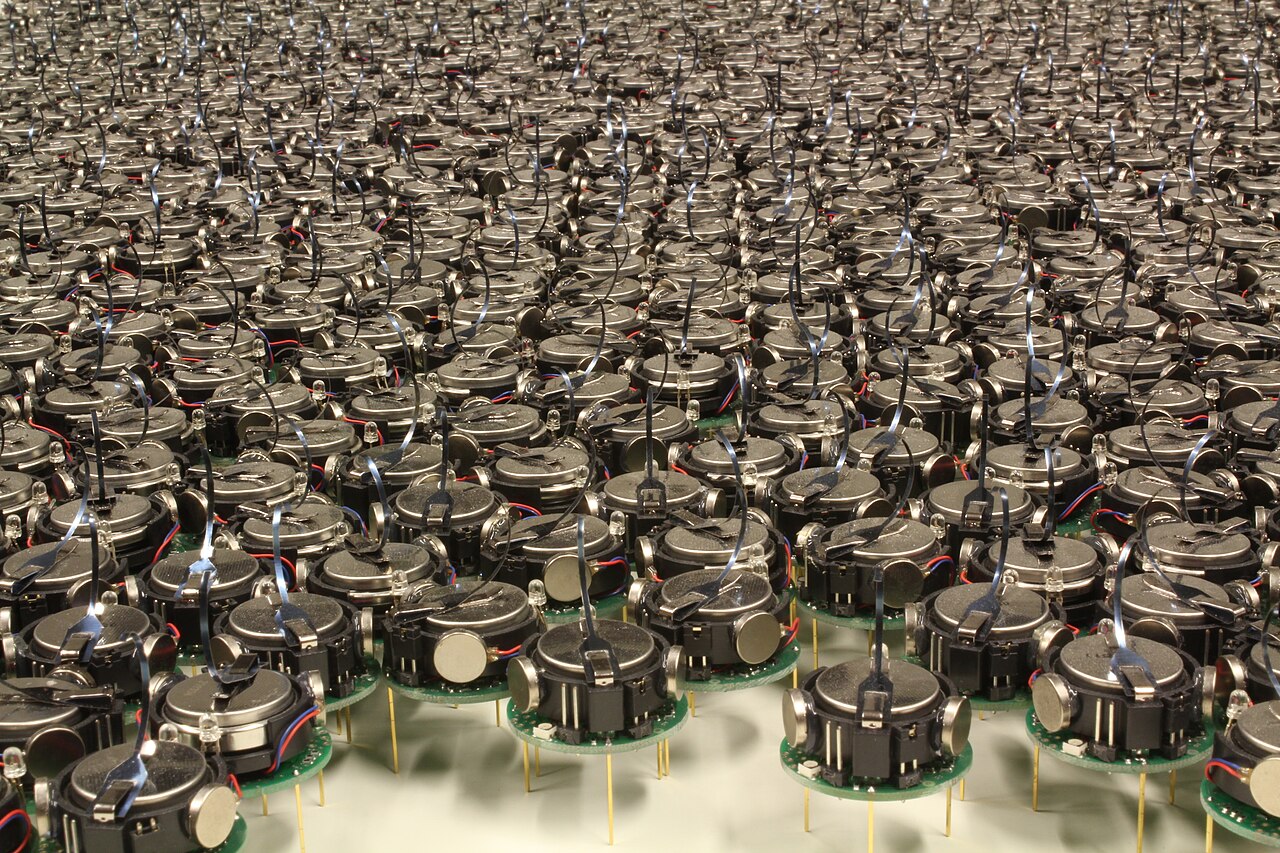 Robotics Primer
September 4, 2026
Swarm Control (Multi-Robot) Primer — Building Flocking, Formation, and Consensus
Swarm control solves problems a single robot can't, using nothing but "simple local rules" applied across many robots. From reproducing flocking with Boids, through consensus algorithms for agreement, to the three approaches to formation control — leader-follower, virtual structures, and behavior-based — this article systematically organizes the field around the divide between centralized and decentralized architectures.
Fundamentals · 13 min Connected & Autonomous Driving
September 3, 2026
Behavior Planning Primer: How FSMs, Behavior Trees, and POMDPs Choose What an Automated Vehicle Does Next
Behavior planning turns uncertain perception into stop, follow, yield, merge, and lane-change decisions, then constrains path planning and MPC. This primer connects FSMs, behavior trees, POMDPs, current ADAS, safety, and testing.
Fundamentals · 11 min
Connected & Autonomous Driving
September 3, 2026
Behavior Planning Primer: How FSMs, Behavior Trees, and POMDPs Choose What an Automated Vehicle Does Next
Behavior planning turns uncertain perception into stop, follow, yield, merge, and lane-change decisions, then constrains path planning and MPC. This primer connects FSMs, behavior trees, POMDPs, current ADAS, safety, and testing.
Fundamentals · 11 min Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min
Connected & Autonomous Driving
September 3, 2026
SAE Driving Automation Levels 0–5 — The Responsibility Boundary Behind ADAS
SAE J3016 is not a score of vehicle intelligence. Learn who performs the dynamic driving task, monitoring, and fallback at Levels 0–5, with ODD, takeover latency, current ADAS, SOTIF, security, and safety evaluation.
Fundamentals · 9 min
Connected & Autonomous Driving
September 3, 2026
V2X Primer — Connecting Vehicles, Roads, Networks, and People Safely
What do V2V, V2I, V2N, and V2P exchange, and how do DSRC/ITS-G5 and C-V2X differ? This primer connects latency, delivery reliability, cooperative perception, PKI, location privacy, fail-safe design, and reproducible testing.
Fundamentals · 7 min
Control Engineering Primer
September 3, 2026
Control Engineering Primer: State Observers and the Linear Kalman Filter
Sensor readings are not the state itself. This primer explains observability, Kalman predict/update equations, covariance, numerical examples, control integration, robot implementation, and fault-safe behavior.
Fundamentals · 5 min
Control Engineering Primer
September 3, 2026
Control Engineering Primer: LQR — State Feedback From Explicit Priorities
LQR derives state-feedback gains from a state-space model and a quadratic cost. This primer covers Riccati equations, observability, PID/MPC tradeoffs, robot implementation, numerical intuition, and safety.
Fundamentals · 5 min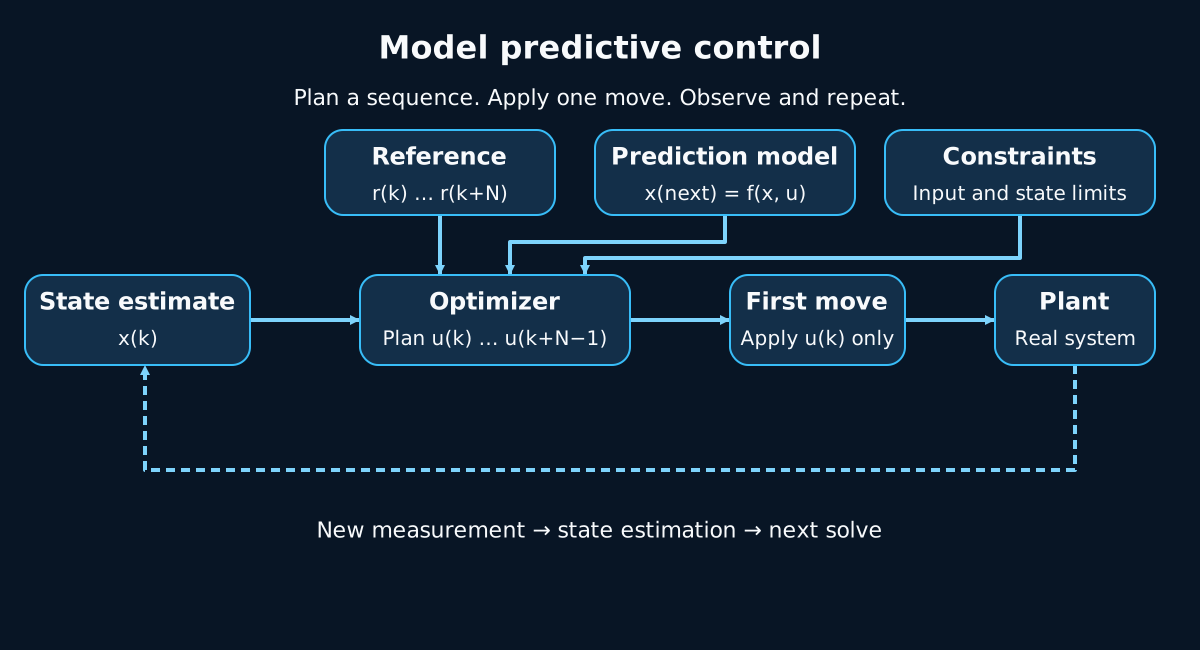 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Model Predictive Control — Acting Within Constraints
Model Predictive Control predicts future behavior with a model, optimizes a constrained input sequence, applies only its first move, and repeats. This primer covers equations, tuning, safety, implementation, and current examples.
Fundamentals · 6 min Control Engineering Primer September 3, 2026Control Engineering Primer: Path Planning — A*, Dijkstra, RRT, RRT*, and PRM
Path planning is not drawing a shortest line. This primer compares grid and continuous-space algorithms while accounting for robot footprint, map uncertainty, computation, SLAM/Nav2 integration, and safety.
Fundamentals · 5 min Control Engineering Primer September 3, 2026Control Engineering Primer: PID Control — Working Across Three Time Scales
PID is not merely three gains. This primer connects its intuition and equations to sampling, saturation, anti-windup, tuning, safety, ROS 2, and real implementation checks.
Fundamentals · 7 min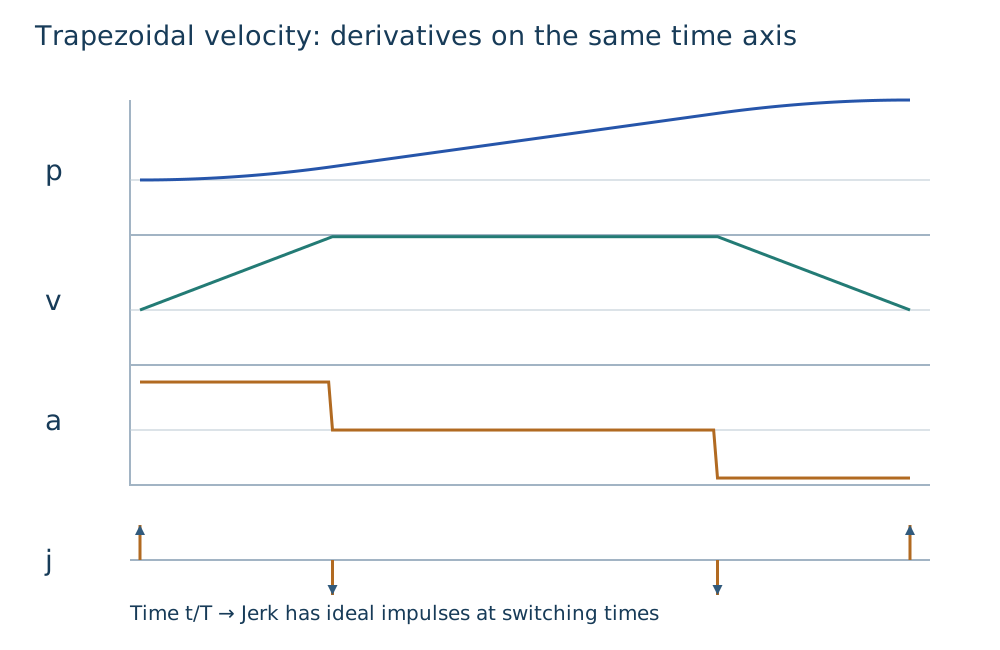 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Trajectory Generation — Minimum Jerk, Quintics, and Trapezoidal Profiles
A path says where to travel; a trajectory says when and with what velocity, acceleration, and jerk. This primer covers minimum-jerk, quintic, trapezoidal profiles, constraints, safety, and ROS 2 integration.
Fundamentals · 4 min
Computer Vision Primer
September 3, 2026
Epipolar Geometry — Reading Depth and Camera Motion from Two Images
Epipolar geometry is the theory that constrains how the same 3D point projects into two images. This article systematically explains the Fundamental Matrix and Essential Matrix, the 8-point and 5-point algorithms, RANSAC, triangulation, the choice between epipolar geometry and homography, calibration, OpenCV/COLMAP implementation, failure conditions, and recent learning-based estimation, with equations and diagrams.
Fundamentals · 16 min Computer Vision Primer
September 3, 2026
Feature Detection Primer
Feature detection selects "places you can find again" in an image and uses them for matching. This article connects the principles of corners, blobs, DoG, FAST, ORB, and SIFT with robustness, evaluation, current tools, and learning-based methods into a single coherent picture.
Fundamentals · 13 min Computer Vision Primer
September 3, 2026
VO/VIO Primer — A Practical Foundation for Estimating Motion from a Camera and an IMU
Visual Odometry (VO) and Visual-Inertial Odometry (VIO) estimate the relative motion of a robot or camera from a sequence of images and inertial measurements. This article works through monocular scale ambiguity, IMU preintegration, initialization, filtering versus optimization, implementations such as VINS-Mono and OpenVINS, evaluation metrics, and failure conditions, with math and diagrams.
Fundamentals · 17 min
Connected & Autonomous Driving
September 3, 2026
HD Maps — Lane-Level Maps for Autonomous Driving
An HD map represents lanes, boundaries, signs, elevation, and connectivity as machine-readable data. This guide explains how it differs from a SLAM map, how localization works, and why freshness and uncertainty matter.
Fundamentals · 5 min
Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min Robotics Primer
September 3, 2026
ArduPilot Primer — State Estimation, Control, and Mission Design for an Autopilot
ArduPilot is an open-source autopilot that implements a vehicle's sensor fusion, attitude/position control, navigation missions, and failsafes. This article covers the differences between Copter, Plane, and Rover, plus EKF, PID, MAVLink, SITL, and real-vehicle safety testing, with diagrams.
Fundamentals · 5 min Robotics Primer
September 3, 2026
Dead Reckoning Primer — Integrating Wheels, IMU, and GNSS to Track a Robot's Motion
Dead reckoning is the foundational technique of updating a robot's pose and position by integrating wheel rotation, IMU readings, and velocity sensors. This article covers differential-drive kinematics, accumulating error, EKF-based correction, and implementations in indoor transport robots and autonomous driving, with equations and diagrams.
Fundamentals · 5 min Robotics Primer
September 3, 2026
ROS 2 Primer — Safely Distributing Robot Control Across Nodes, Topics, and DDS
ROS 2 is a robotics middleware that splits sensing, perception, planning, and control into separate processes and connects them via DDS communication. This article covers nodes, topics, services, actions, QoS, TF2, lifecycle, implementation and debugging, along with the differences from ROS 1 and real-world operational cautions, with diagrams.
Fundamentals · 5 min