#Hands-on
 Control Engineering Primer
September 8, 2026
Lab
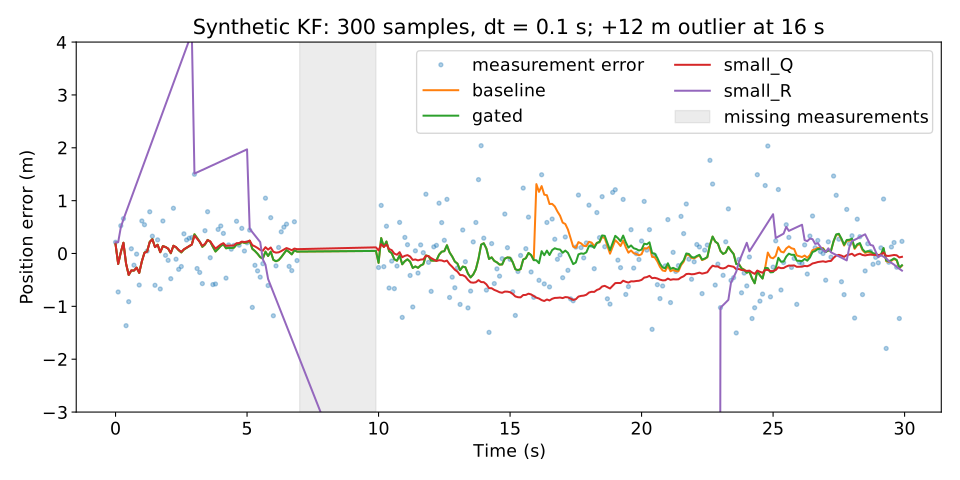
Run a Kalman filter in Python: noise, missing data and outliers
Compare Q, R and outlier gating on one synthetic trajectory using estimation error and rejected observations.
Hands-on · 3 min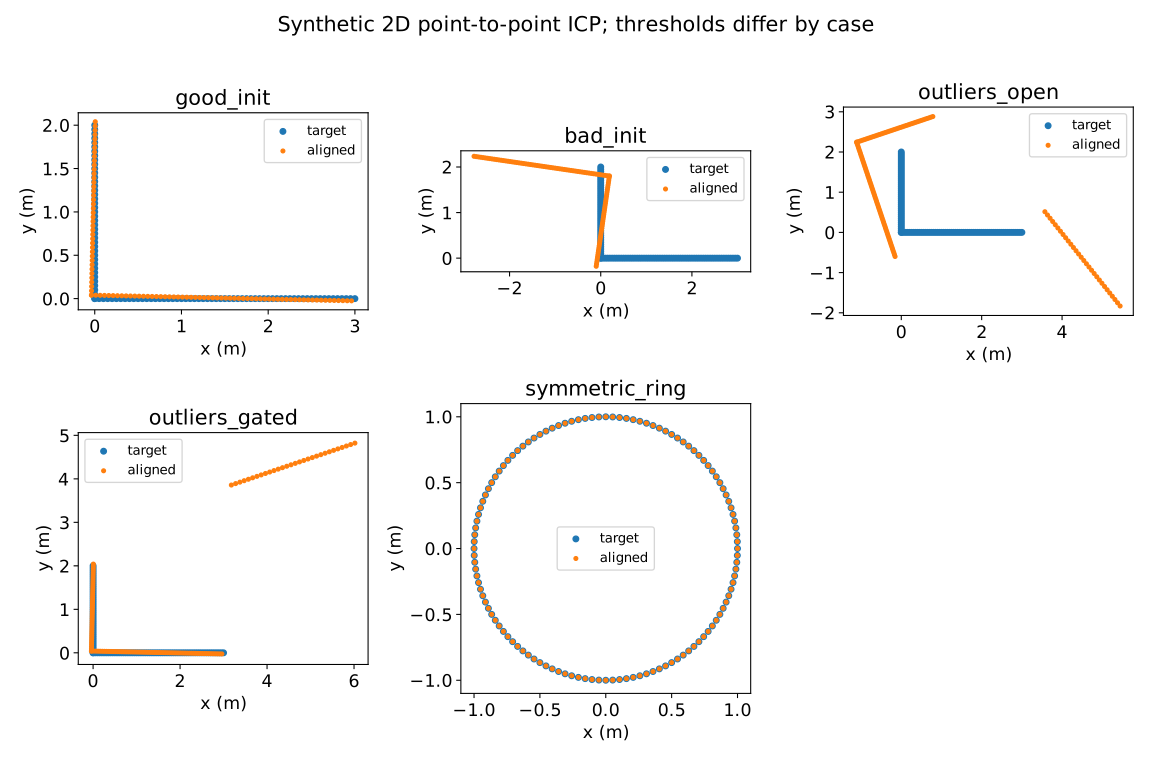 Robotics Primer
September 8, 2026
Lab
Why ICP fails: initialization, outliers and symmetric geometry
Run 2D registration and distinguish residuals, correspondence coverage and true pose error.
Hands-on · 3 min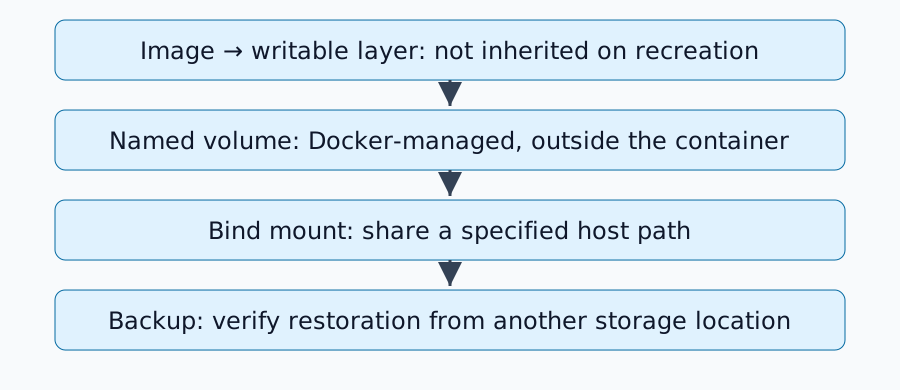 Notes
September 8, 2026
Lab
Where Docker data lives: layers, volumes and backups
Distinguish writable layers, named volumes and bind mounts, then verify persistence across container recreation.
Hands-on · 3 min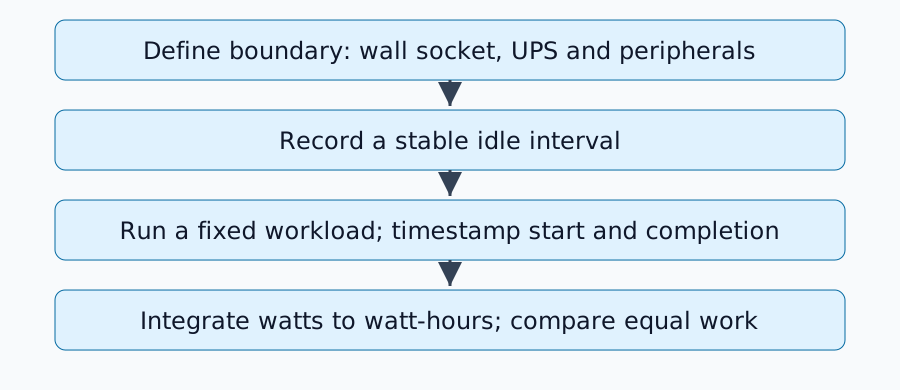 Notes
September 8, 2026
Lab
Measure home-server power: idle, inference and storage
Log wall-side active power consistently and compare idle demand and energy per completed workload.
Hands-on · 4 min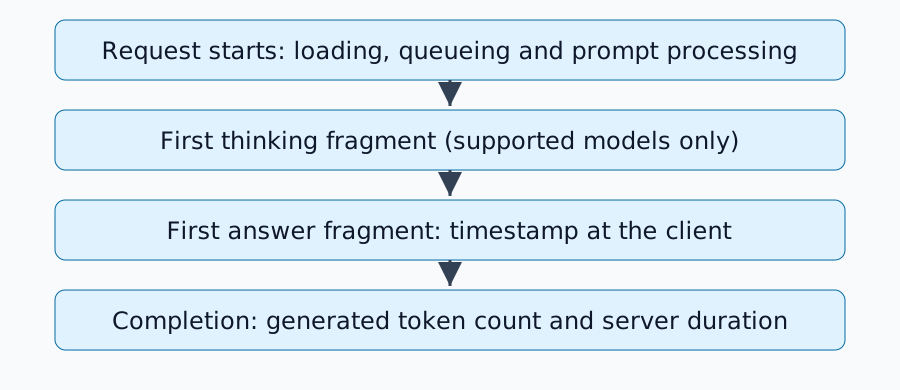 Machine Learning Primer
September 8, 2026
Lab
Benchmark local LLMs: first response, generation rate and memory
Measure first answer content separately from generation rate and control residency, caching and memory conditions.
Hands-on · 3 min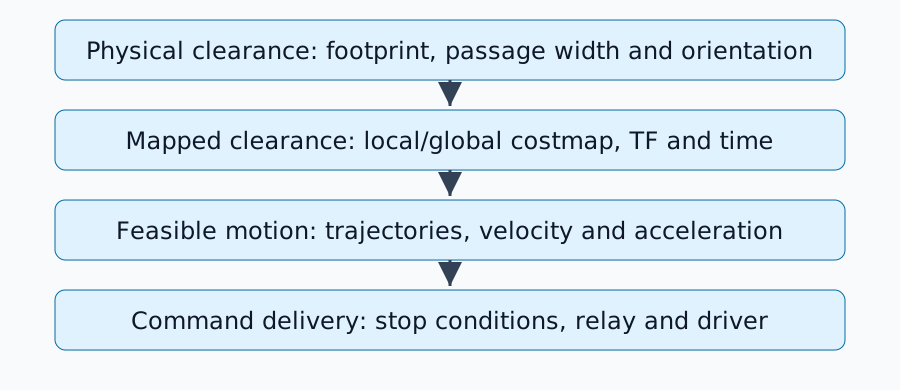 Robotics Primer
September 8, 2026
Lab
Nav2 has a path but will not move: a diagnostic workflow
Inspect geometry, costmaps, control feasibility and command delivery to explain a stopped robot.
Hands-on · 4 min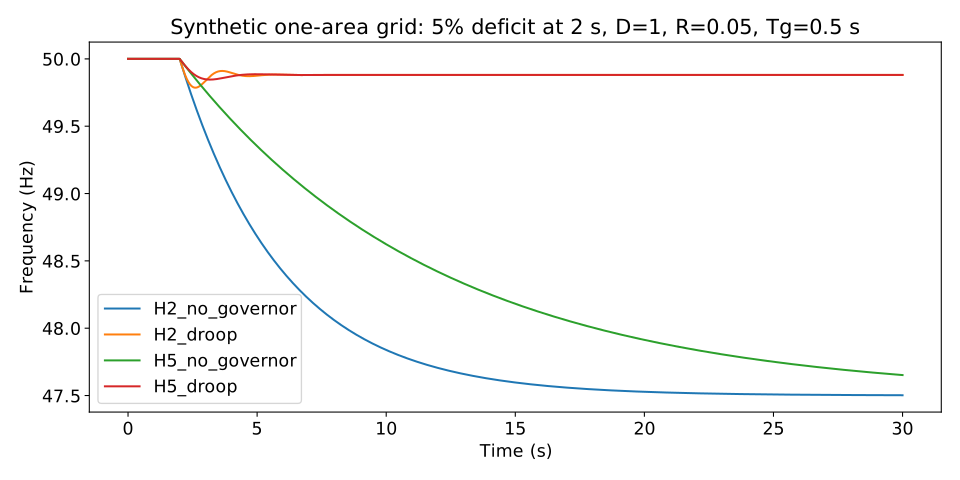 Power Engineering Primer
September 8, 2026
Lab
Simulate grid frequency: imbalance, inertia and primary response
Use a simple one-area model to separate inertia from primary frequency response after a supply deficit.
Hands-on · 3 min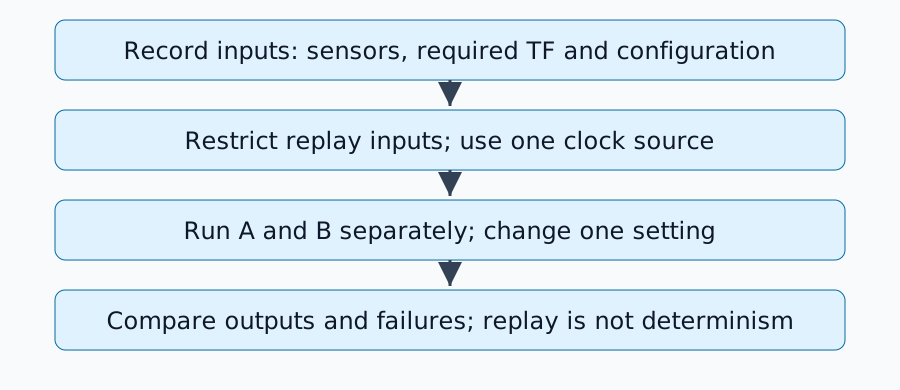 Robotics Primer
September 8, 2026
Lab
Reproduce robot failures with rosbag2: inputs, TF and time
Build controlled replay comparisons and diagnose duplicate TF publishers and mixed time sources.
Hands-on · 5 min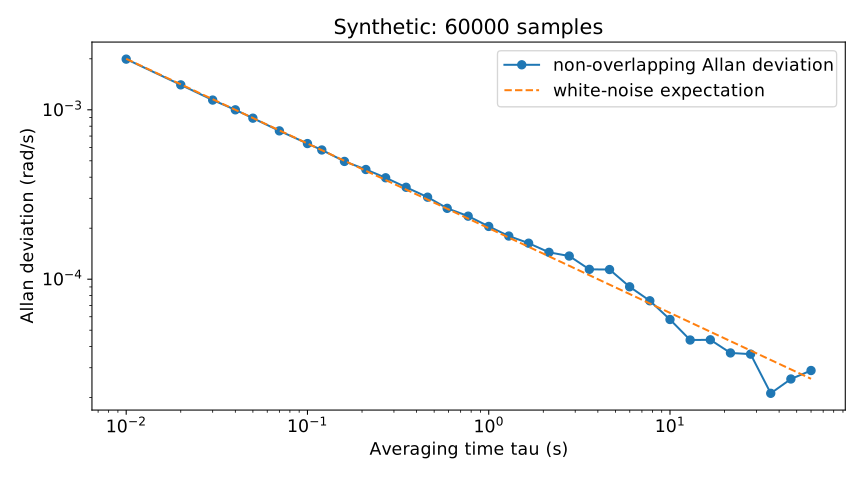 Sensors & Hardware
September 8, 2026
Lab
Read a stationary IMU log: bias, scatter and Allan deviation
Compute mean, standard deviation and non-overlapping Allan deviation without overinterpreting a short gyro log.
Hands-on · 3 min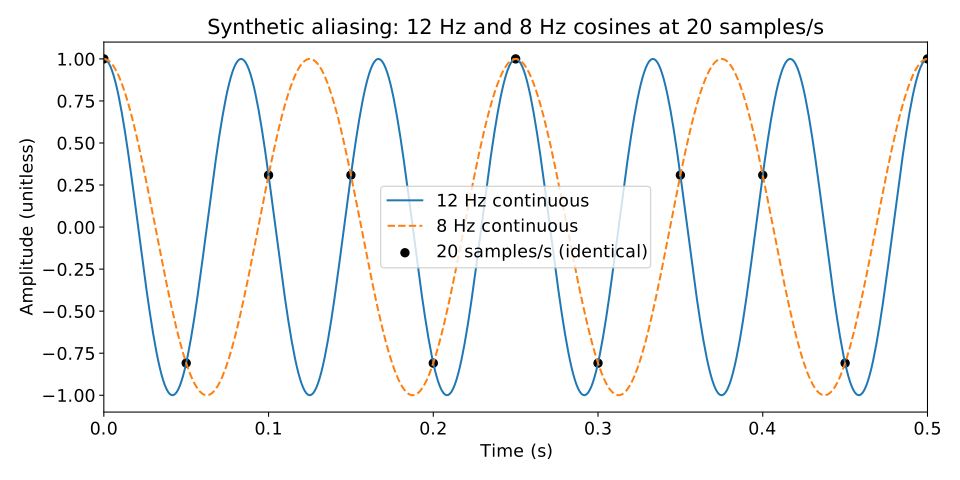 Sensors & Hardware
September 8, 2026
Lab
Sampling and aliasing: why faster polling is not enough
Reproduce identical samples from 12 Hz and 8 Hz signals and distinguish ODR, bandwidth, polling and decimation.
Hands-on · 2 min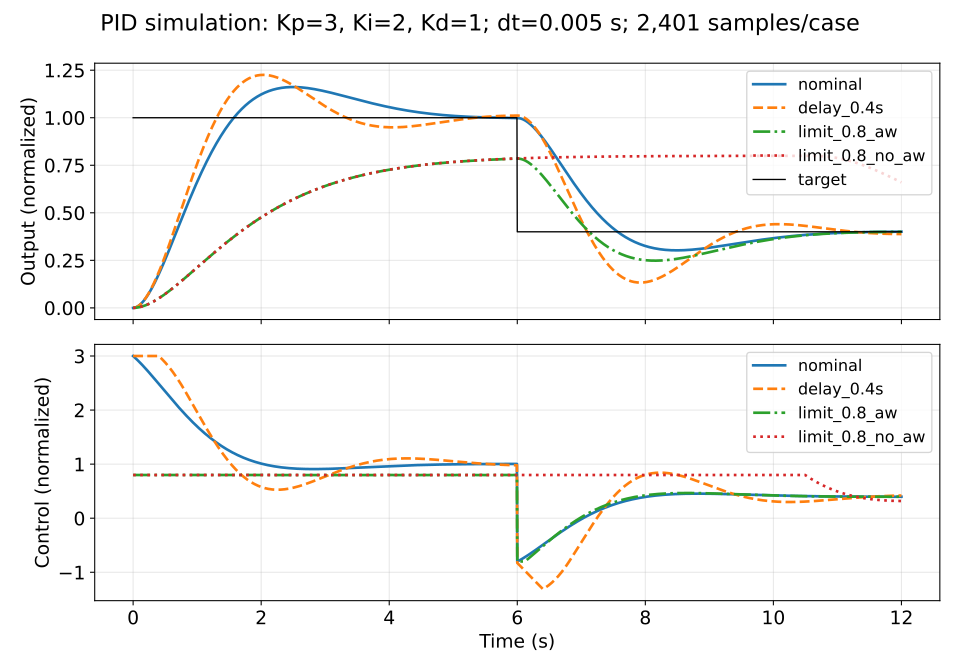 Control Engineering Primer
September 7, 2026
Lab
Experiment with PID in Python — gains, delay and saturation
Reproduce how measurement delay, actuator limits and integral windup change PID tracking on the same second-order model.
Hands-on · 2 min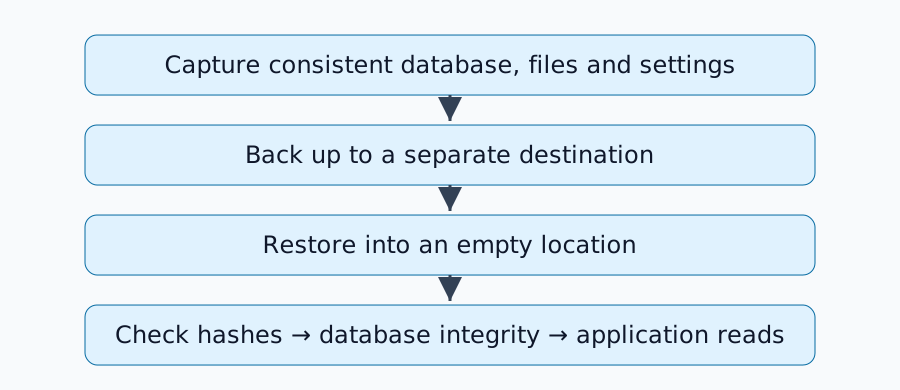 Notes
September 7, 2026
Lab
Home-server backup and recovery — a small restore exercise
Distinguish restored files from usable application data with a small SQLite exercise, then map the checks to a real server.
Hands-on · 4 min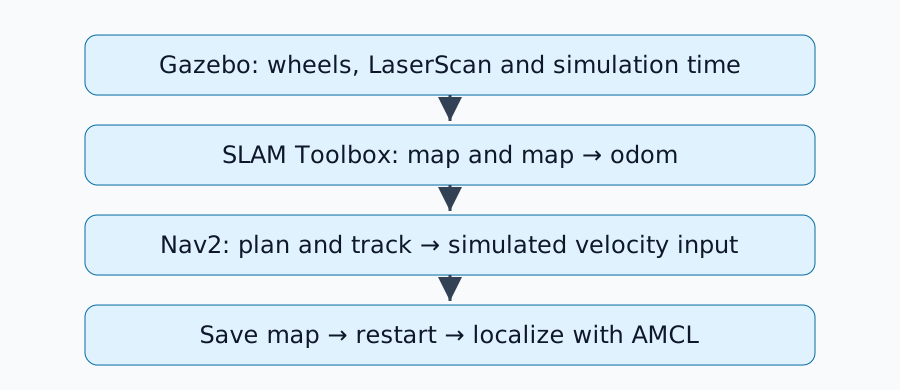 Robotics Primer
September 7, 2026
Lab
From mapping to navigation in ROS 2 — a minimal Jazzy and Nav2 procedure
Use the Jazzy simulation to check mapping, map saving, reloading and goal navigation as separate steps.
Hands-on · 4 min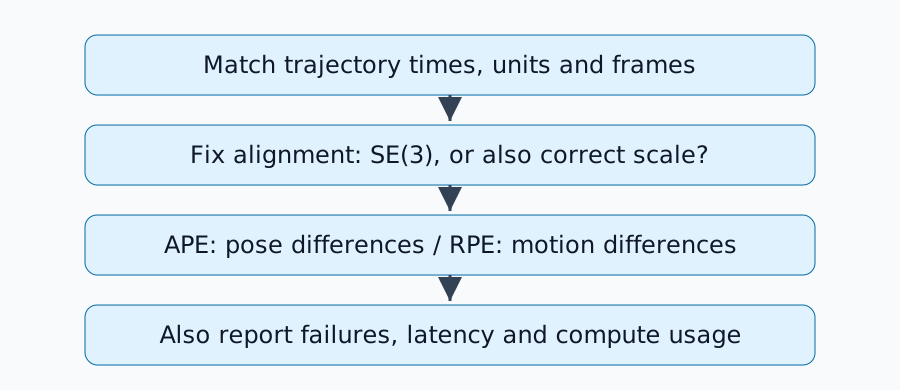 Robotics Primer
September 7, 2026
Lab
How to evaluate SLAM — ATE, RPE, runtime and failures
Use synthetic trajectories to distinguish absolute and relative errors, then define matching, alignment and failure reporting for an evaluation.
Hands-on · 3 min