#Robotics
 Robotics Primer
September 7, 2026
Hydraulic Systems Primer — From Pascal's Principle to Force Control in Robots
Why can a small input move a hydraulic excavator's massive arm? This article treats the pump, control valves, cylinder, hydraulic fluid, sensors, and controller as a single closed loop, covering the pressure/flow/efficiency equations, current technology in construction and agricultural machinery, and electro-hydraulic conversion and current research, with diagrams.
Fundamentals · 8 min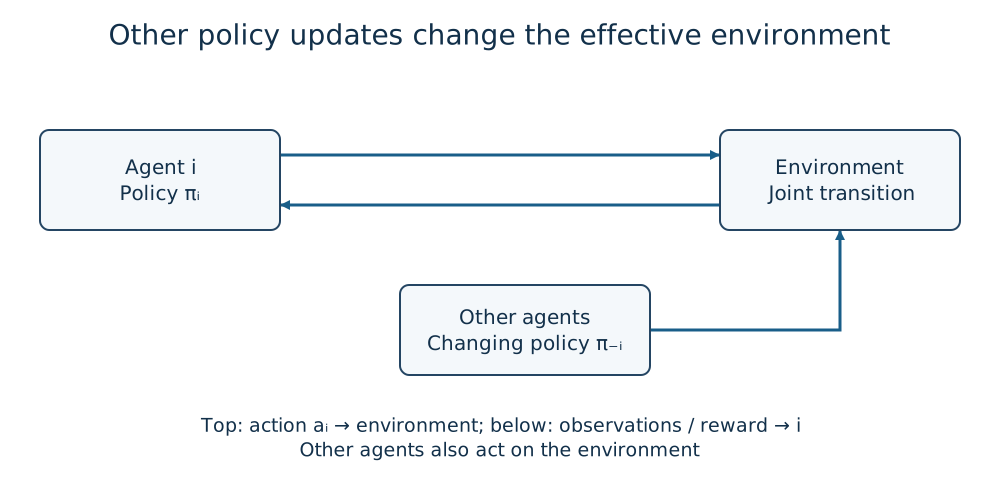 Reinforcement Learning Primer
September 4, 2026
Multi-Agent Reinforcement Learning Primer — Optimizing in a World Where the Other Side Is Learning Too
When multiple agents learn at the same time, a single-agent MDP no longer holds. This article organizes non-stationarity, cooperative/competitive/mixed settings, CTDE, the credit-assignment problem, and MADDPG and QMIX, with equations and diagrams.
Fundamentals · 8 min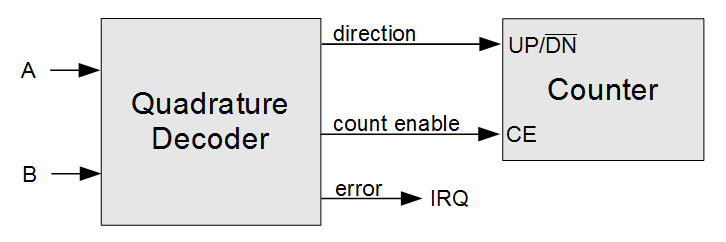 Sensors & Hardware
September 4, 2026
How Rotary Encoders Work — Optical and Magnetic
We compare the two operating principles behind the rotary encoder — optical, which reads position by interrupting light, and magnetic, which reads the direction of a magnetic field — from a motor's shaft angle and speed sensor.
Fundamentals · 13 min Sensors & Hardware
September 4, 2026
How Temperature Sensors Work, and the Products That Define the Category — Thermocouples, PT100, DS18B20
Every temperature sensor does the same one thing — turns heat into an electrical signal — but the physics underneath splits into four separate families: the Seebeck effect in thermocouples, the resistance-temperature relationship in RTDs and thermistors, the bandgap behavior of semiconductor ICs, and the Stefan-Boltzmann law behind infrared radiation thermometers. This piece traces the history from Seebeck's 1821 misunderstanding, through the Callendar-Van Dusen equation that calibrates PT100 sensors, to a spec comparison of real ICs like the DS18B20, TMP117, and MLX90614, and a real-world case of an F1 car reading tire temperature with 12 non-contact IR sensors.
Fundamentals · 16 min Control Engineering Primer
September 3, 2026
Control Engineering Primer: State Observers and the Linear Kalman Filter
Sensor readings are not the state itself. This primer explains observability, Kalman predict/update equations, covariance, numerical examples, control integration, robot implementation, and fault-safe behavior.
Fundamentals · 5 min
Control Engineering Primer
September 3, 2026
Control Engineering Primer: LQR — State Feedback From Explicit Priorities
LQR derives state-feedback gains from a state-space model and a quadratic cost. This primer covers Riccati equations, observability, PID/MPC tradeoffs, robot implementation, numerical intuition, and safety.
Fundamentals · 5 min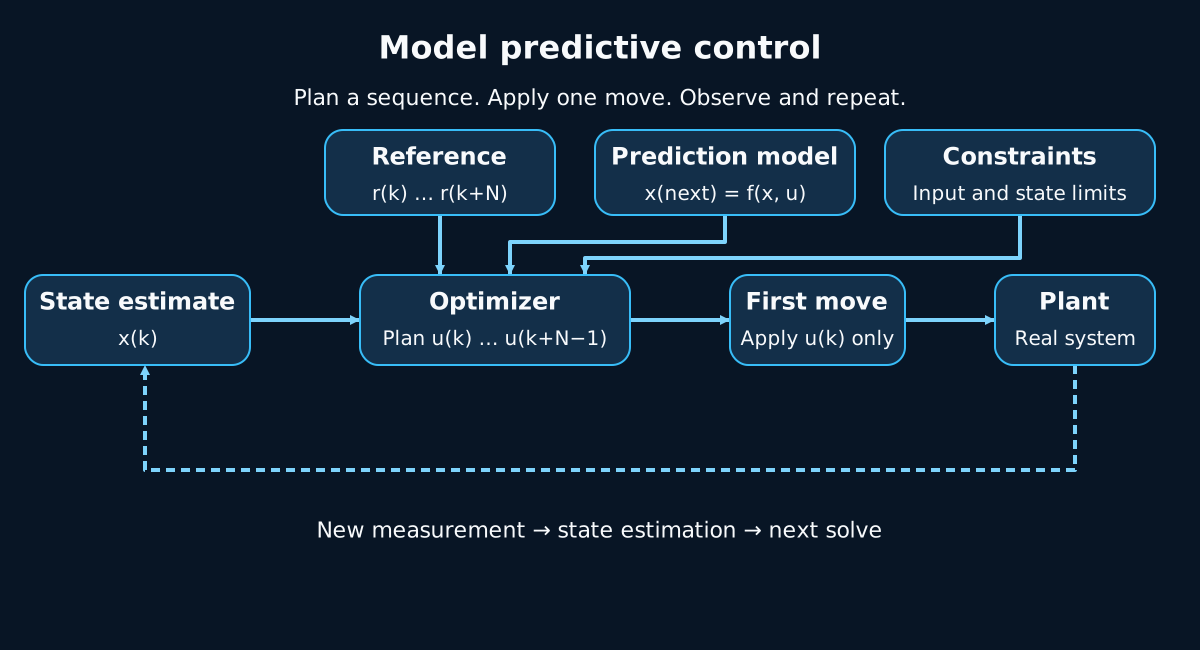 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Model Predictive Control — Acting Within Constraints
Model Predictive Control predicts future behavior with a model, optimizes a constrained input sequence, applies only its first move, and repeats. This primer covers equations, tuning, safety, implementation, and current examples.
Fundamentals · 6 min Control Engineering Primer September 3, 2026Control Engineering Primer: Path Planning — A*, Dijkstra, RRT, RRT*, and PRM
Path planning is not drawing a shortest line. This primer compares grid and continuous-space algorithms while accounting for robot footprint, map uncertainty, computation, SLAM/Nav2 integration, and safety.
Fundamentals · 5 min Control Engineering Primer September 3, 2026Control Engineering Primer: PID Control — Working Across Three Time Scales
PID is not merely three gains. This primer connects its intuition and equations to sampling, saturation, anti-windup, tuning, safety, ROS 2, and real implementation checks.
Fundamentals · 7 min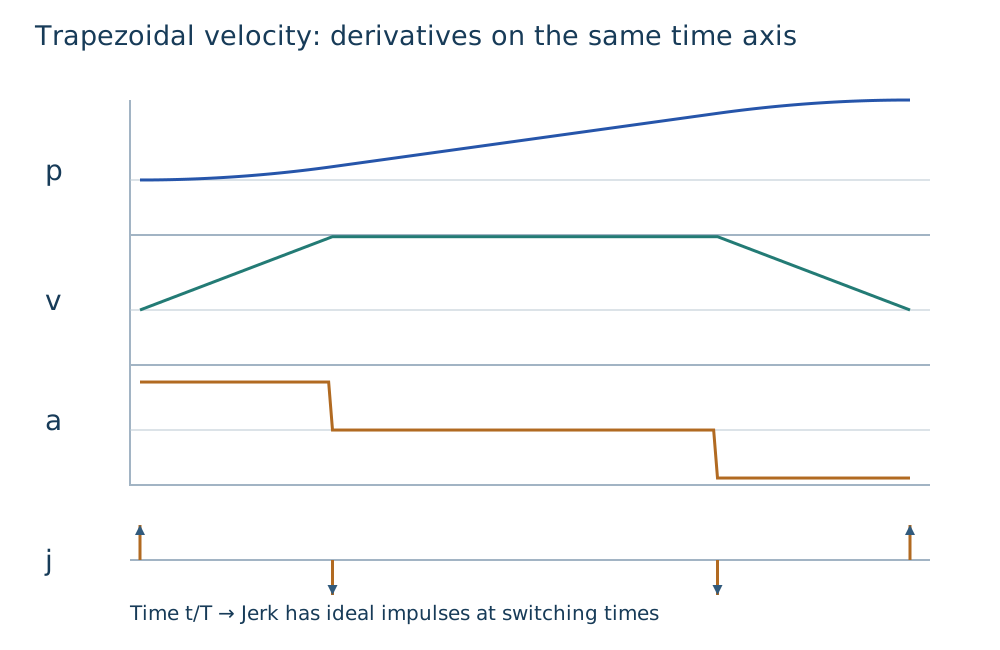 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Trajectory Generation — Minimum Jerk, Quintics, and Trapezoidal Profiles
A path says where to travel; a trajectory says when and with what velocity, acceleration, and jerk. This primer covers minimum-jerk, quintic, trapezoidal profiles, constraints, safety, and ROS 2 integration.
Fundamentals · 4 min Computer Vision Primer
September 3, 2026
VO/VIO Primer — A Practical Foundation for Estimating Motion from a Camera and an IMU
Visual Odometry (VO) and Visual-Inertial Odometry (VIO) estimate the relative motion of a robot or camera from a sequence of images and inertial measurements. This article works through monocular scale ambiguity, IMU preintegration, initialization, filtering versus optimization, implementations such as VINS-Mono and OpenVINS, evaluation metrics, and failure conditions, with math and diagrams.
Fundamentals · 17 min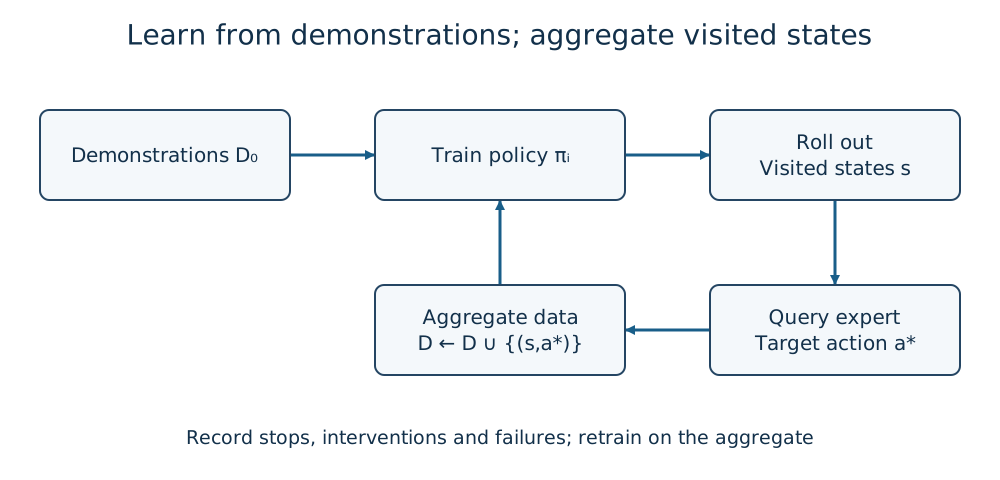 Reinforcement Learning Primer
September 3, 2026
Reinforcement Learning Primer: Imitation Learning and Inverse Reinforcement Learning
Behavior Cloning, DAgger, and inverse reinforcement learning use demonstrations when rewards are hard to write. This primer covers covariate shift, reward inference, VLA connections, evaluation, safety, and data provenance.
Fundamentals · 5 min Reinforcement Learning Primer September 3, 2026Reinforcement Learning Basics — MDPs, Bellman Equations, and Exploration for Robots
Reinforcement learning is a closed loop in which an agent chooses actions from observations and maximizes delayed rewards. This primer explains MDPs, value functions, policies, Bellman equations, exploration versus exploitation, reward design, and the path from simulation to a real robot.
Fundamentals · 6 min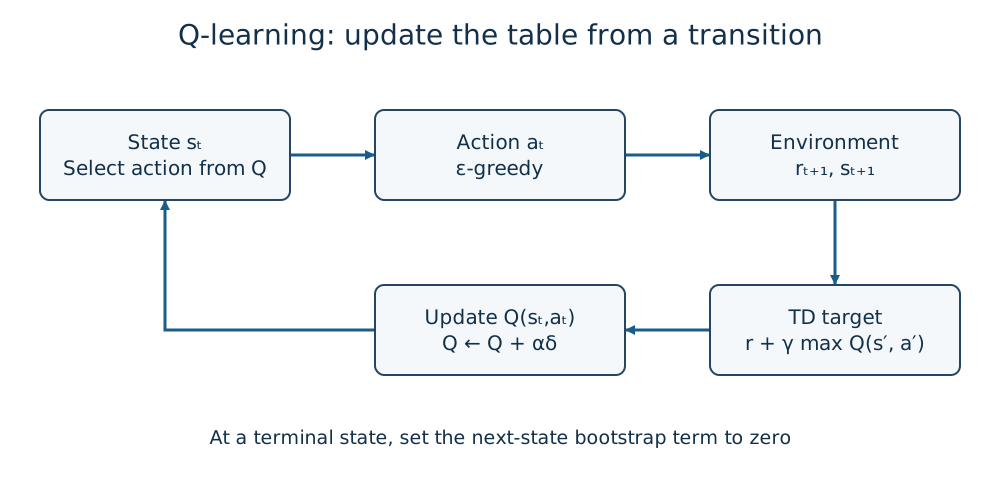 Reinforcement Learning Primer
September 3, 2026
Q-Learning and DQN — From a Q-Table to Deep Reinforcement Learning
Q-learning updates action values with the Bellman optimality target. This primer follows the path from a tabular Q-table to a Deep Q-Network, explaining experience replay, target networks, overestimation, and safe placement in a robot stack.
Fundamentals · 5 min Robotics Primer
September 3, 2026
ROS 2 Primer — Safely Distributing Robot Control Across Nodes, Topics, and DDS
ROS 2 is a robotics middleware that splits sensing, perception, planning, and control into separate processes and connects them via DDS communication. This article covers nodes, topics, services, actions, QoS, TF2, lifecycle, implementation and debugging, along with the differences from ROS 1 and real-world operational cautions, with diagrams.
Fundamentals · 5 min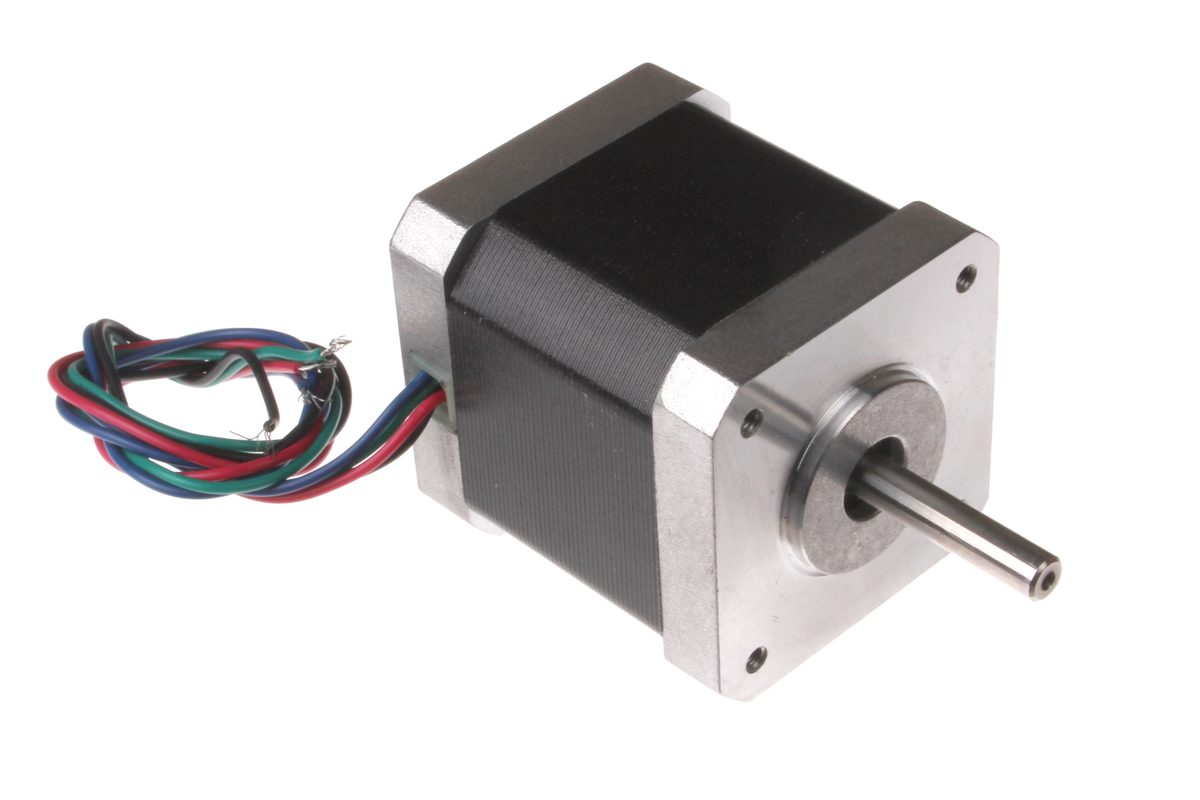 Sensors & Hardware
September 3, 2026
How Actuators Work — BLDC, Stepper, Servo Motors
We compare the actuators that serve as a robot's "muscles" across three angles — the BLDC motor, the stepper motor, and the servo motor. These three aren't actually a parallel classification; motor construction (BLDC/stepper) and control architecture (servo) are two different axes that get conflated. Untangling that confusion, we trace the real torque/response/control tradeoffs from NASA's brush-wear-in-vacuum problem to the birth of Wiener's cybernetics.
Fundamentals · 15 min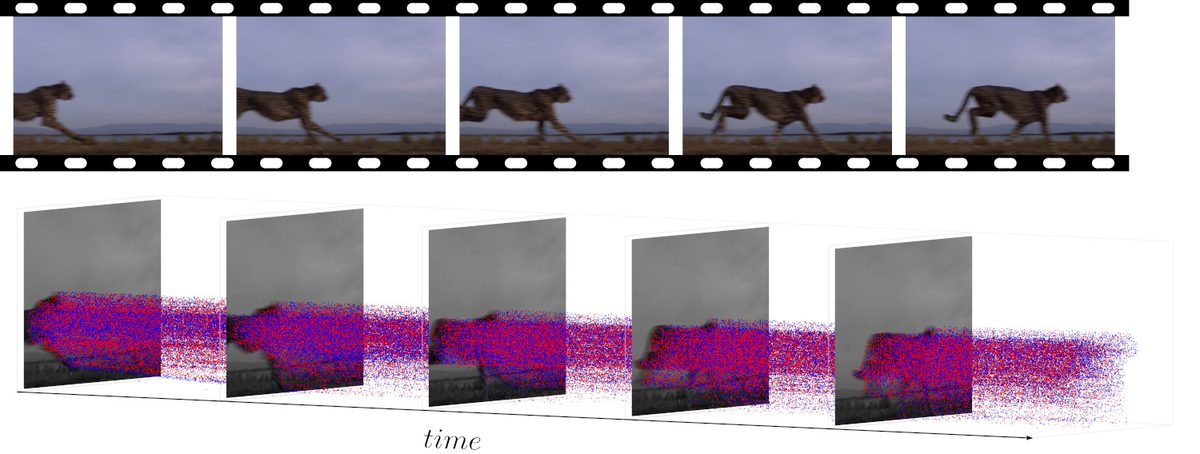 Sensors & Hardware
September 3, 2026
How Event Cameras (DVS) Work and Key Products — Prophesee, iniVation
Unlike conventional cameras that keep capturing frames (still images) at fixed intervals, event cameras (Dynamic Vision Sensor, DVS) have each pixel independently report only the instant its brightness changes, at microsecond resolution. We trace the real chips — Prophesee Metavision, iniVation DVXplorer/DAVIS, Samsung DVS-Gen4 — the neuromorphic-engineering lineage from 1988's silicon retina research to iniVation's 2024 acquisition, the stereo-event-camera autonomous-driving dataset DSEC, and SLAM research running onboard UAVs.
Fundamentals · 13 min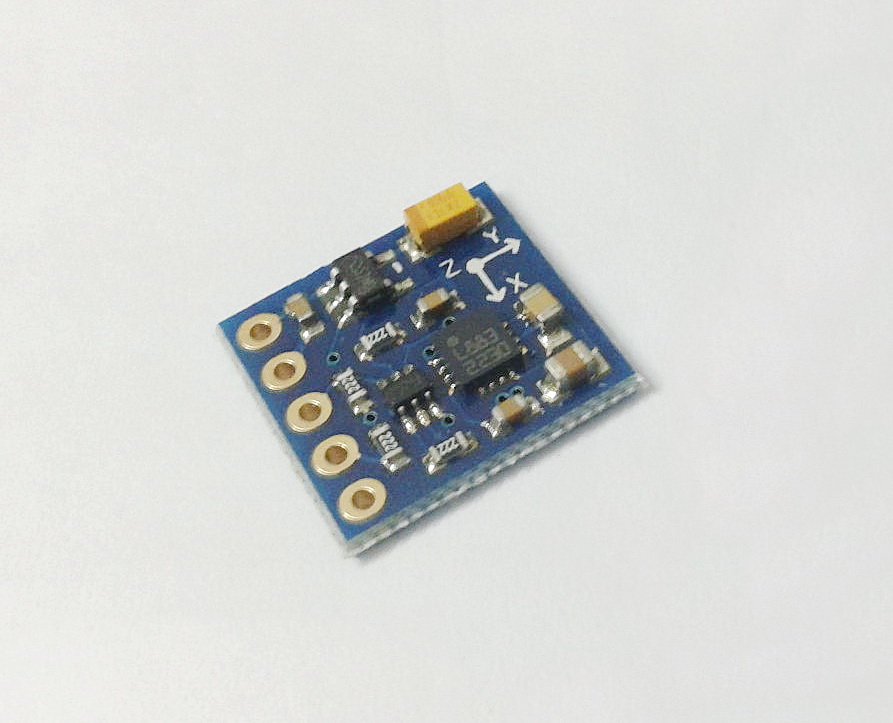 Sensors & Hardware
September 3, 2026
How Magnetometers Work and the Key Products — Bosch, ST, Honeywell
The magnetometer, which senses the direction of Earth's magnetic field to derive heading, is the one sensor that keeps returning an absolute-direction external reference as long as it has power — from a smartphone's electronic compass, to yaw-angle correction on a drone, to attitude control on a CubeSat. This article lays out the four underlying physical principles — the Hall effect, AMR, GMR, and fluxgate — compares real chip specs across the Bosch BMM150, STMicroelectronics LIS3MDL, and Honeywell HMC5883L, covers hard-iron/soft-iron error and its calibration, AHRS sensor fusion with an IMU, and the technology's history from ore prospecting through WWII submarine hunting and lunar exploration to today's CubeSat attitude control.
Fundamentals · 14 min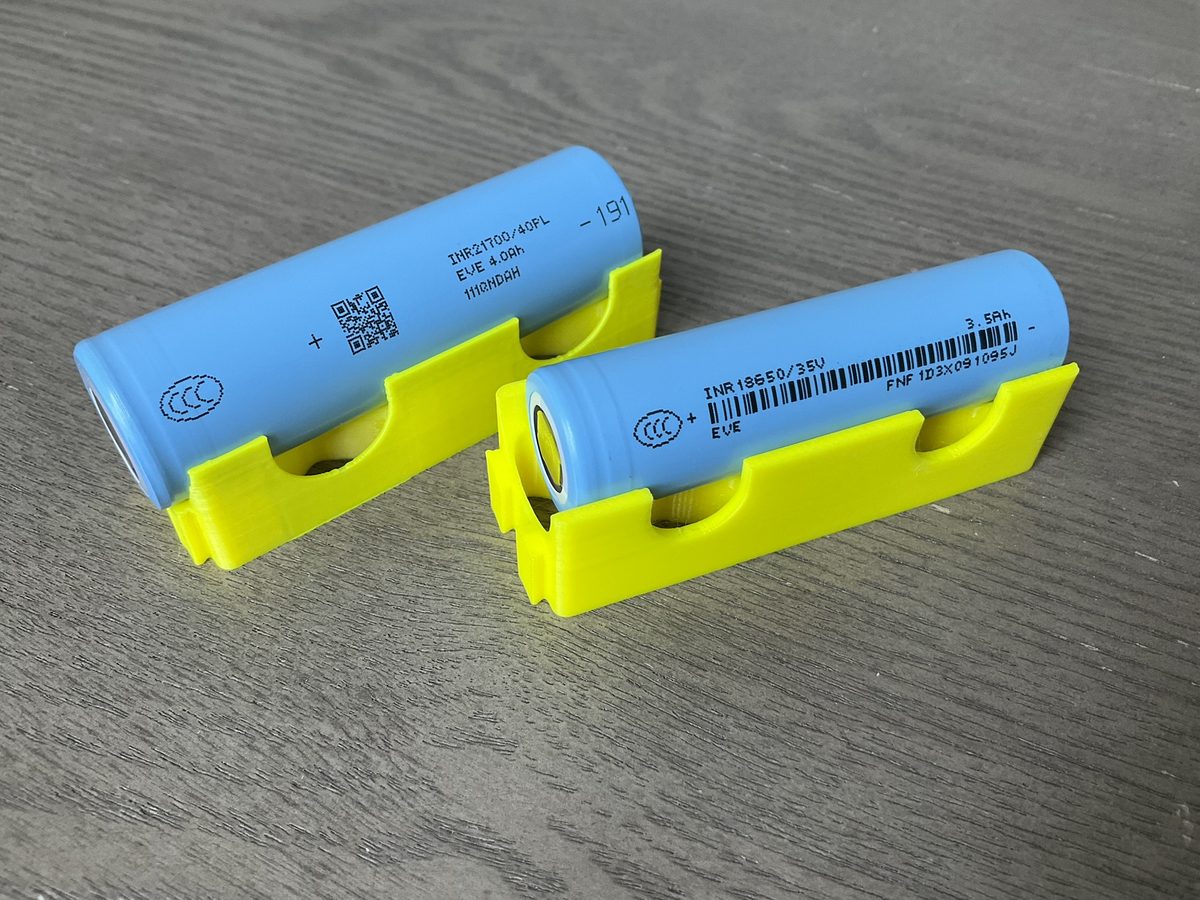 Sensors & Hardware
September 2, 2026
How Batteries and BMS Work — Molicel, DJI, Samsung SDI
What determines a robot's or drone's range and safety isn't the motor or the sensor suite — it's the battery and its BMS (Battery Management System). From the electrochemistry of lithium-ion cells to cell balancing and protection circuits, we compare real specs from Molicel's high-discharge cells, DJI's intelligent flight batteries, and Samsung SDI's push into next-generation solid-state batteries — and look at what the Boeing 787 fire taught the industry about the limits of a BMS.
Fundamentals · 12 min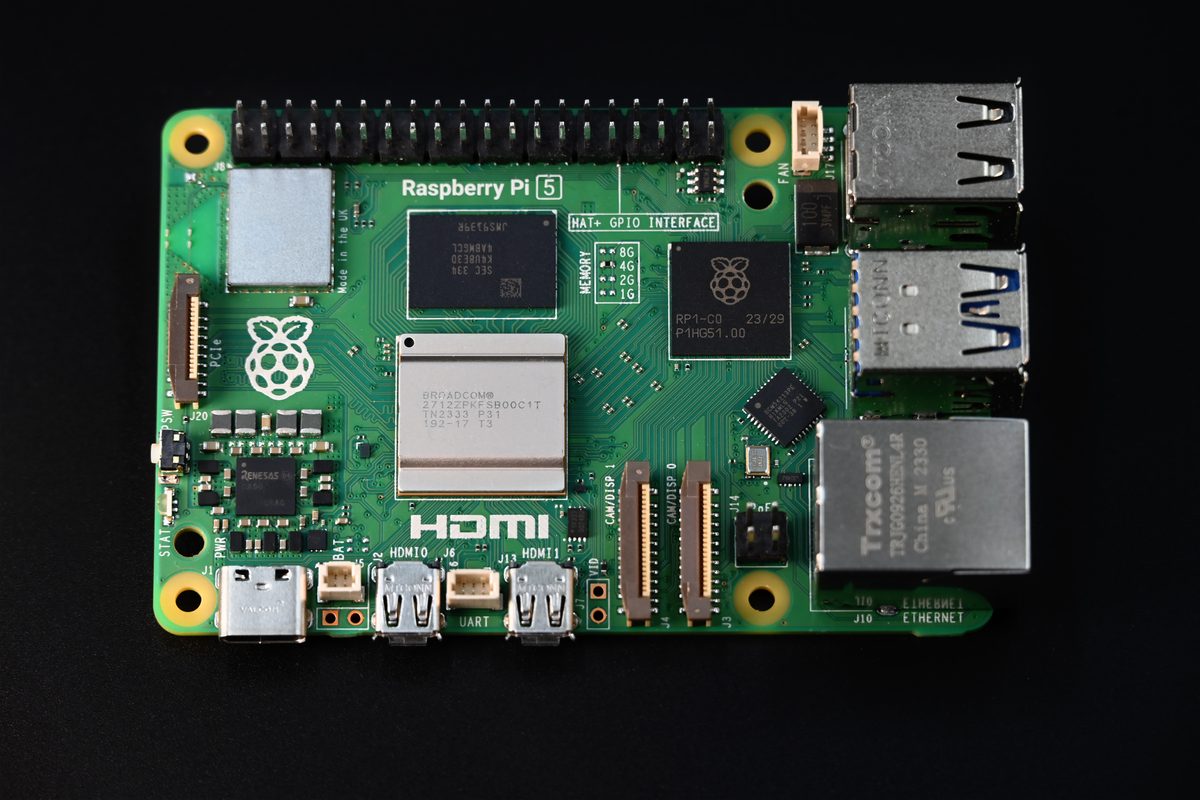 Sensors & Hardware
September 2, 2026
How SBCs Work and Key Products — Raspberry Pi 5, Jetson, Coral
We compare the embedded computers that serve as a robot's "brain" across three design philosophies — the general-purpose SoC of the Raspberry Pi 5, the GPU-integrated AI computer of NVIDIA Jetson Orin, and the dedicated ASIC of Google Coral. From what the TOPS/W efficiency metric actually means, to why the newbot project chose a general-purpose SoC, to the real 2026 story of an AI-datacenter DRAM crunch hitting the hobbyist SBC market.
Fundamentals · 13 min Technology Trends
August 26, 2026
Technology Trends in VLA (Vision-Language-Action)
Vision-Language-Action folds camera input and natural-language instructions into a single model that outputs robot actions directly. From RT-2 to OpenVLA to Physical Intelligence's π0 lineage, surveying the spread of a design philosophy that refuses to separate perception from control.
Trends · 9 min
Sensors & Hardware
August 10, 2026
How IMUs Work and Key Products — Xsens, Bosch, Analog Devices
An IMU pairs an accelerometer with a gyroscope to directly sense a vehicle's own translational acceleration and rotational rate. Unlike cameras or LiDAR, it depends on nothing external — but that self-containment comes with an inescapable fate: error accumulates over time (drift). We work through the MEMS gyroscope principle, Allan-variance noise analysis, the grading scale from consumer chips to navigation-grade modules, and Xsens's MTi series product strategy.
Fundamentals · 10 min Sensors & Hardware
August 4, 2026
How Depth Cameras Work and Key Products — RealSense, Kinect, Orbbec
Active stereo projects a pattern with an infrared emitter and does stereo matching; structured light reads depth from how a known pattern distorts; time-of-flight reads distance directly from a phase shift — three coexisting approaches to depth cameras. We look at the principles behind each and real examples from the Intel RealSense D435i, Microsoft Kinect, Orbbec Femto Bolt, and iPhone TrueDepth, and trace how Israeli startup PrimeSense's technology gave birth to Kinect, got acquired by Apple, and was reborn as Face ID.
Fundamentals · 8 min