Tag · 5 entries
#Fundamentals
 Powertrain & Mechanical Engineering
September 8, 2026
Lab
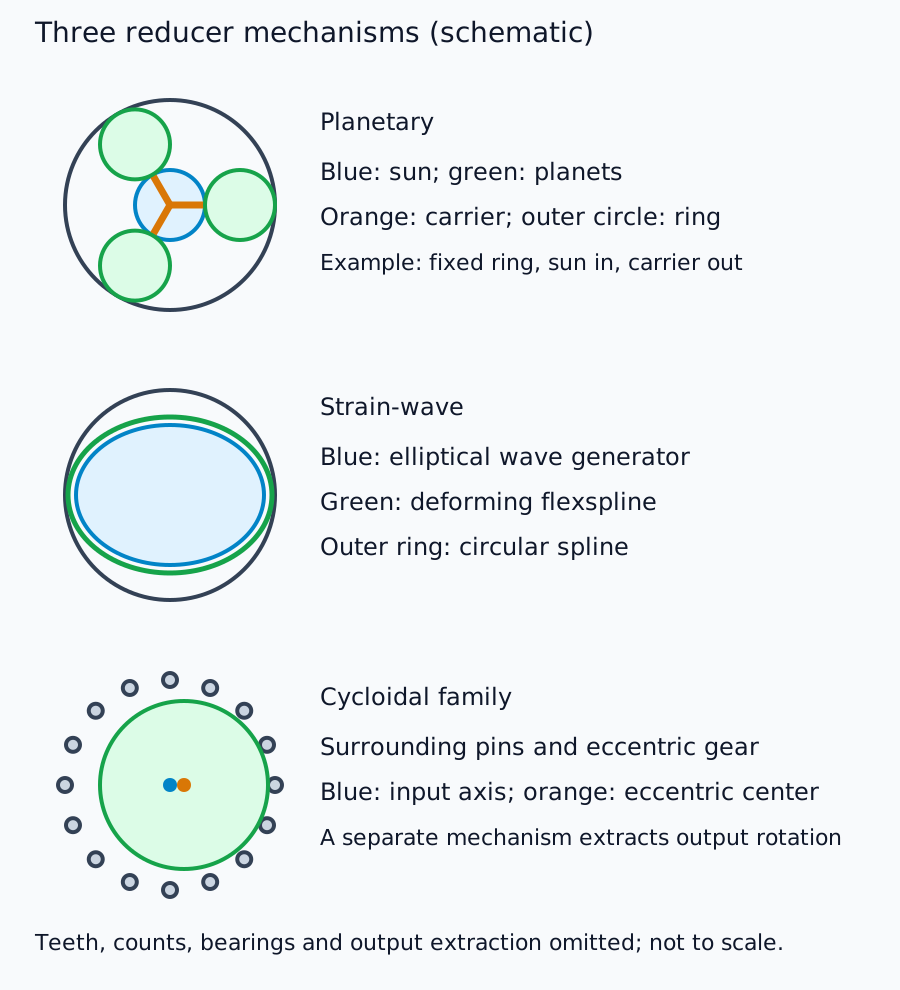
Robot reducers: planetary, strain-wave and cycloidal mechanisms
Compare three mechanisms and connect speed, torque and inertia with selection criteria beyond backlash.
Fundamentals · 5 min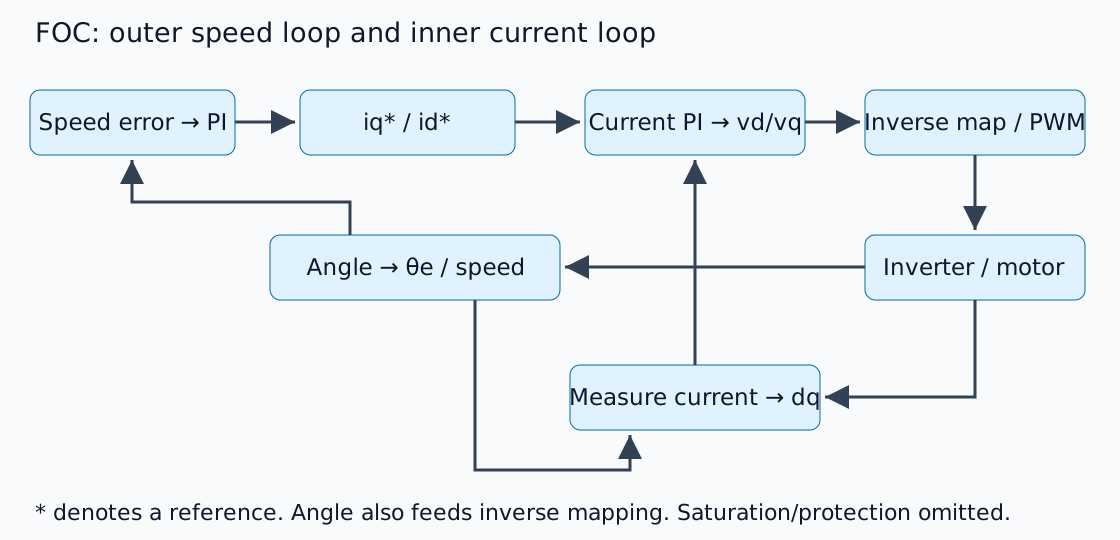 Power Electronics Primer
September 8, 2026
Lab
From motor speed control to FOC: current, torque and nested loops
Understand how speed control requests current and how FOC connects rotating coordinates, electrical angle and limits.
Fundamentals · 4 min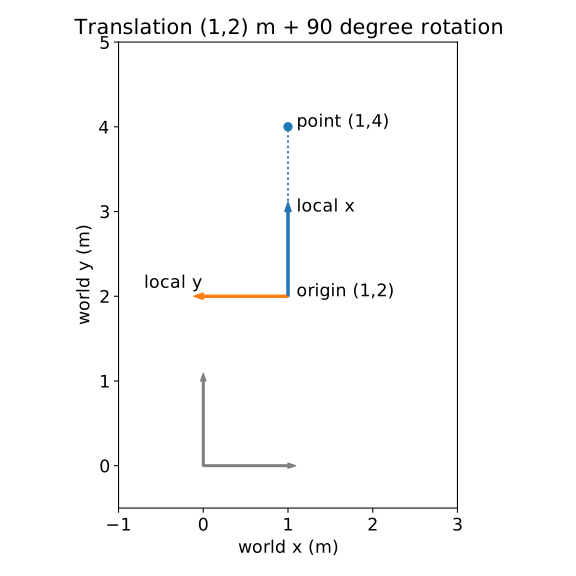 Robotics Primer
September 8, 2026
Lab
Robot coordinate transforms: matrices, quaternions and TF
Use a numeric example to connect rotation, translation, inverse transforms, quaternions and ROS frames.
Fundamentals · 3 min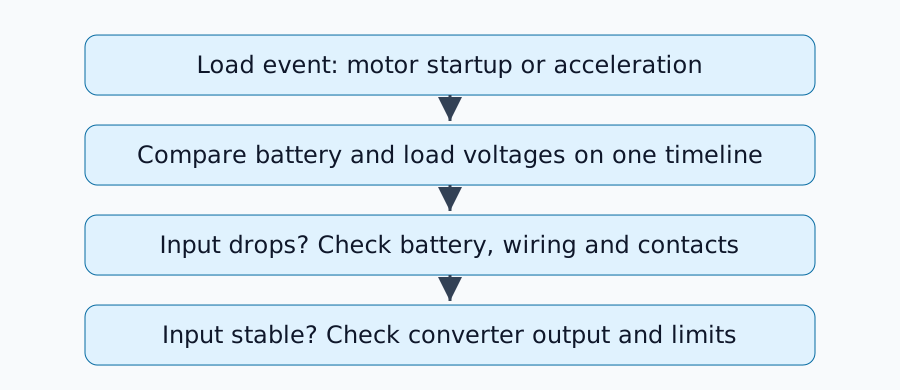 Sensors & Hardware
September 7, 2026
Lab
Robot power design — diagnosing computer resets during motor startup
Relate motor load changes to voltage drops and locate faults across the battery, wiring, converter and computer.
Fundamentals · 5 min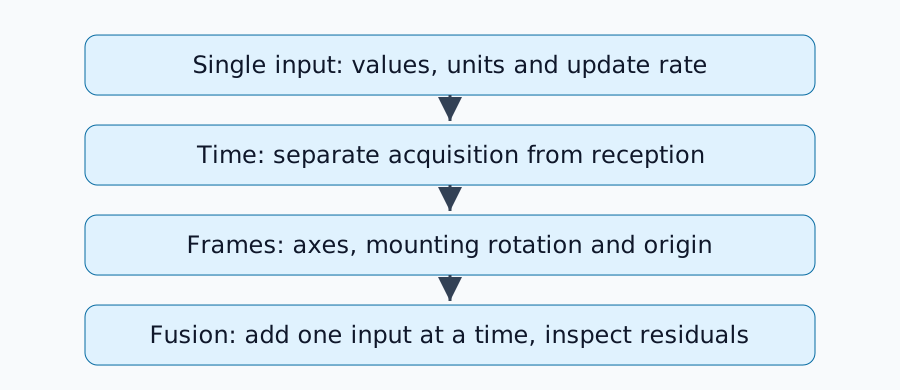 Robotics Primer
September 7, 2026
Lab
Why sensor fusion fails — timing, frames and extrinsic calibration
Diagnose fusion failures through timestamps, coordinate frames, mounting geometry and covariance.
Fundamentals · 4 min