#LiDAR
 Robotics Primer
September 6, 2026
Sensor Fusion Primer — Building One World Model From Many Sensors
A camera is strong on meaning, a LiDAR is strong on geometry, an IMU is strong on motion — and each has its own blind spot. From the probabilistic and optimization-based math that fuses them (Kalman Filters, Factor Graphs) to concrete pairings like VIO (Camera×IMU), LIO (LiDAR×IMU), and BEV Fusion (Camera×LiDAR), a systematic tour of how Sensor Fusion turns several sensors into a single world model.
Fundamentals · 15 min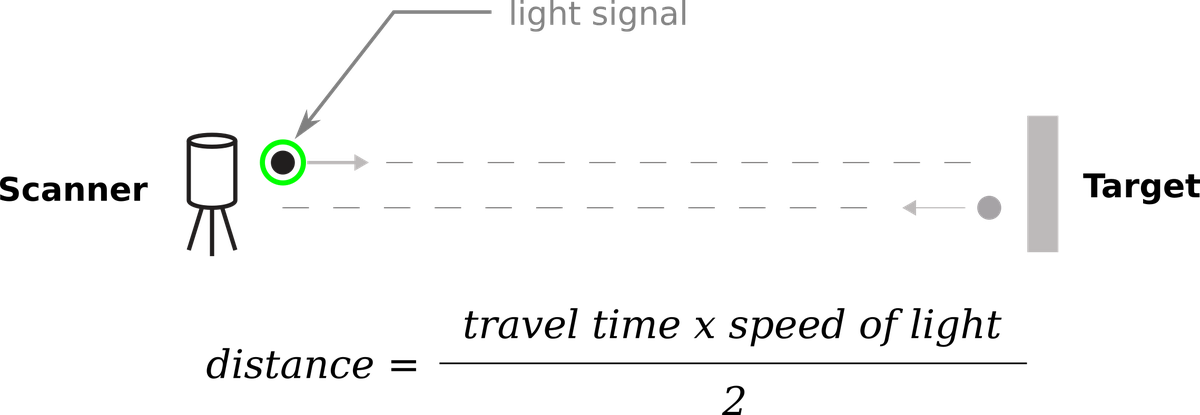 Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min
Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min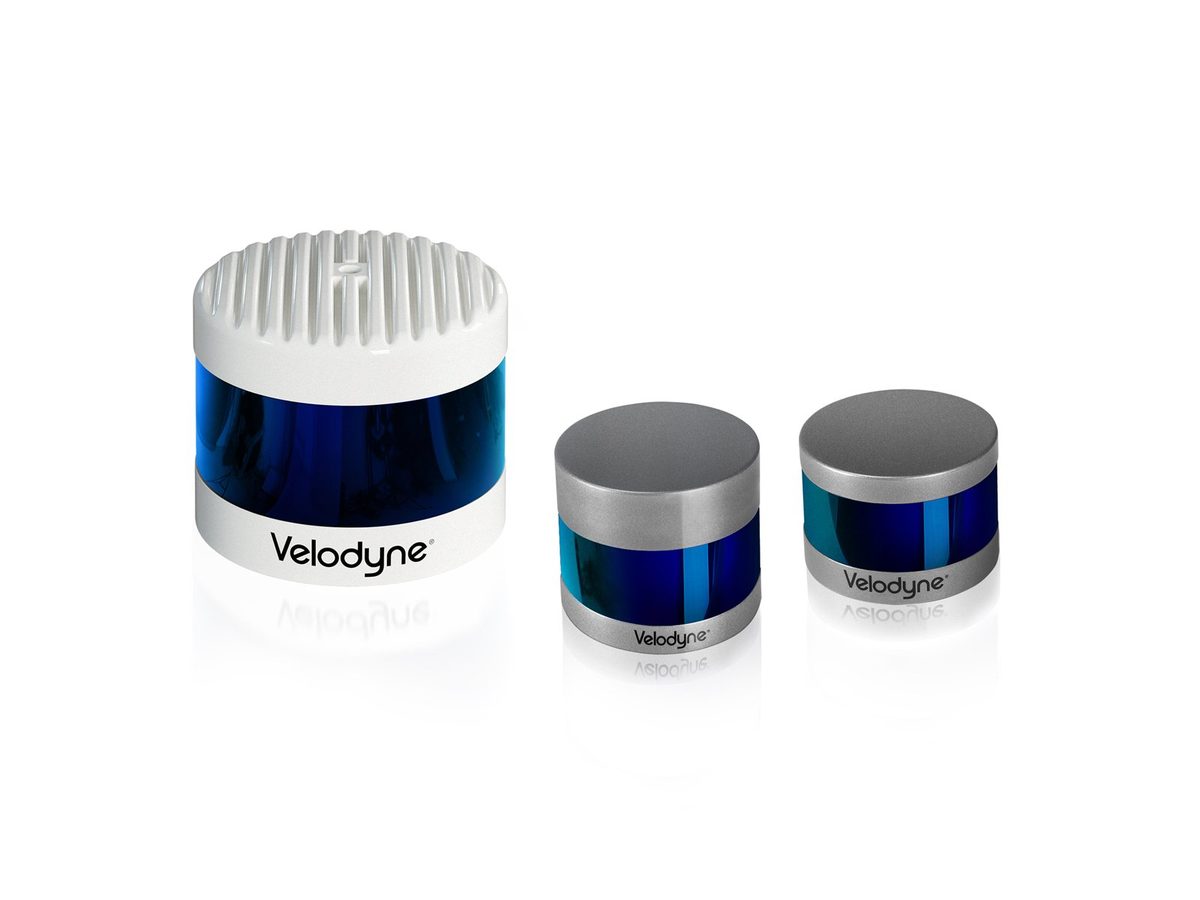 Sensors & Hardware
July 19, 2026
How LiDAR Works and Key Products — Livox, Velodyne, Hesai
LiDAR measures distance from the round-trip time of light, from the rotating Velodyne Puck to the non-rotating Livox Mid-360S that drove costs down, to the Chinese players Hesai and RoboSense. We compare real specs from actual products in production — and trace the industry's real backstory, from the DARPA Grand Challenge to the DJI spinoff to the collapse of Volvo's deal with Luminar.
Fundamentals · 10 min