#SLAM
 Computer Vision Primer
September 7, 2026
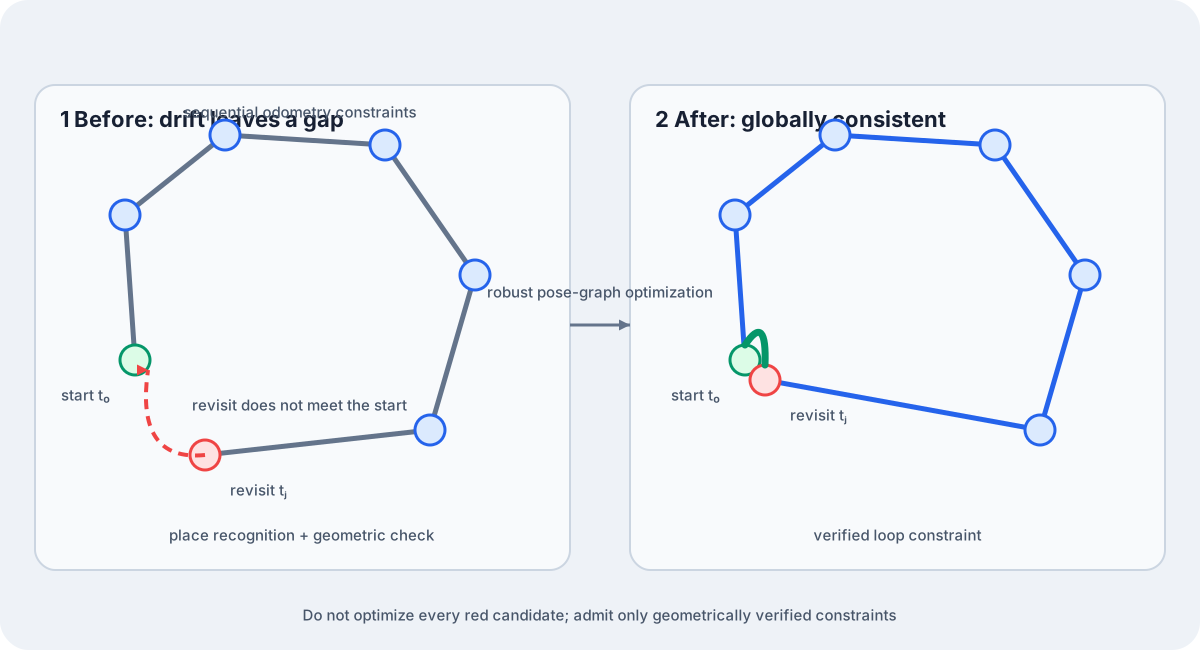
Loop Closure Primer — Fixing a SLAM System's Drift All at Once, Around a Loop
Loop closure is the process of recognizing that a robot has returned to a previously visited place, and distributing the accumulated self-localization error across the whole map. This article systematically explains place recognition, image retrieval, geometric verification, pose-graph optimization, defenses against false positives, and current SLAM implementations and research.
Fundamentals · 5 min Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min Control Engineering Primer September 3, 2026Control Engineering Primer: Path Planning — A*, Dijkstra, RRT, RRT*, and PRM
Path planning is not drawing a shortest line. This primer compares grid and continuous-space algorithms while accounting for robot footprint, map uncertainty, computation, SLAM/Nav2 integration, and safety.
Fundamentals · 5 min
Connected & Autonomous Driving
September 3, 2026
HD Maps — Lane-Level Maps for Autonomous Driving
An HD map represents lanes, boundaries, signs, elevation, and connectivity as machine-readable data. This guide explains how it differs from a SLAM map, how localization works, and why freshness and uncertainty matter.
Fundamentals · 5 min
Connected & Autonomous Driving
September 3, 2026
Occupancy Grid Mapping — Turning LiDAR and Camera Evidence into Traversability
An occupancy grid divides space into cells and represents occupied, free, and unknown space probabilistically. Learn Bayesian and log-odds updates, inverse sensor models, ray casting, dynamic decay, 3D voxels, SLAM, costmaps, and planning.
Fundamentals · 8 min Technology Trends
July 17, 2026
Technology Trends in SLAM
From filter-based methods to graph optimization, and now to learning-based, AI-native approaches. Tracing the lineage of SLAM (simultaneous self-localization and mapping) and where current research stands.
Trends · 7 min