#Control Engineering
 Robotics Primer
September 7, 2026
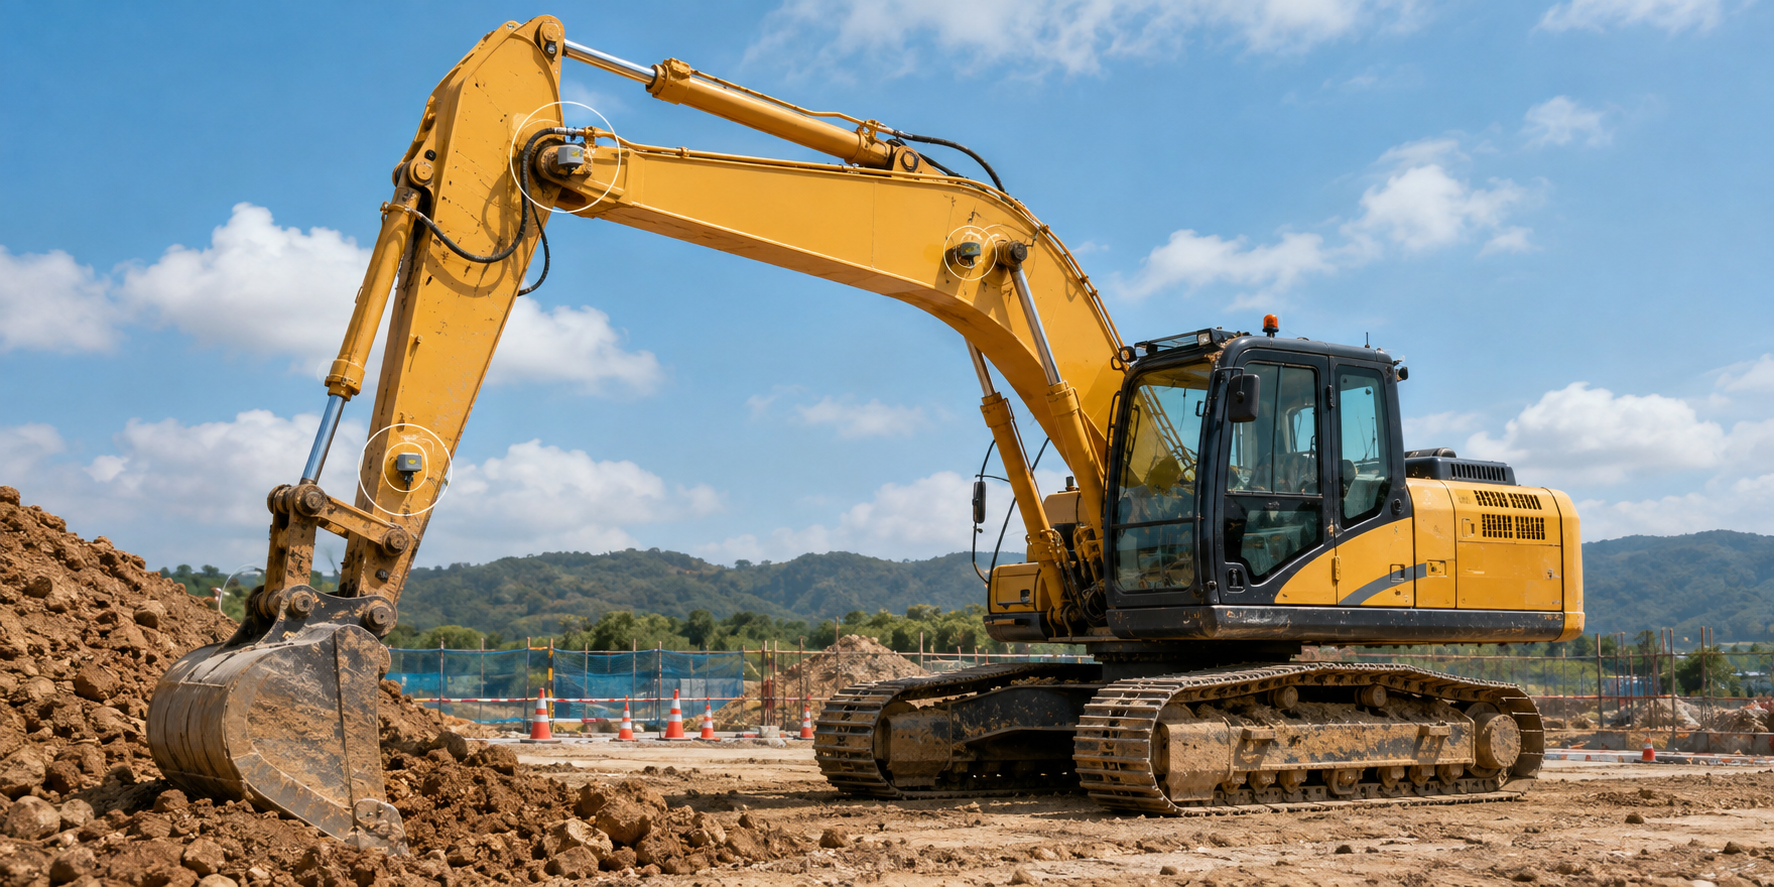
Hydraulic Systems Primer — From Pascal's Principle to Force Control in Robots
Why can a small input move a hydraulic excavator's massive arm? This article treats the pump, control valves, cylinder, hydraulic fluid, sensors, and controller as a single closed loop, covering the pressure/flow/efficiency equations, current technology in construction and agricultural machinery, and electro-hydraulic conversion and current research, with diagrams.
Fundamentals · 8 min Control Engineering Primer
September 3, 2026
Control Engineering Primer: State Observers and the Linear Kalman Filter
Sensor readings are not the state itself. This primer explains observability, Kalman predict/update equations, covariance, numerical examples, control integration, robot implementation, and fault-safe behavior.
Fundamentals · 5 min
Control Engineering Primer
September 3, 2026
Control Engineering Primer: LQR — State Feedback From Explicit Priorities
LQR derives state-feedback gains from a state-space model and a quadratic cost. This primer covers Riccati equations, observability, PID/MPC tradeoffs, robot implementation, numerical intuition, and safety.
Fundamentals · 5 min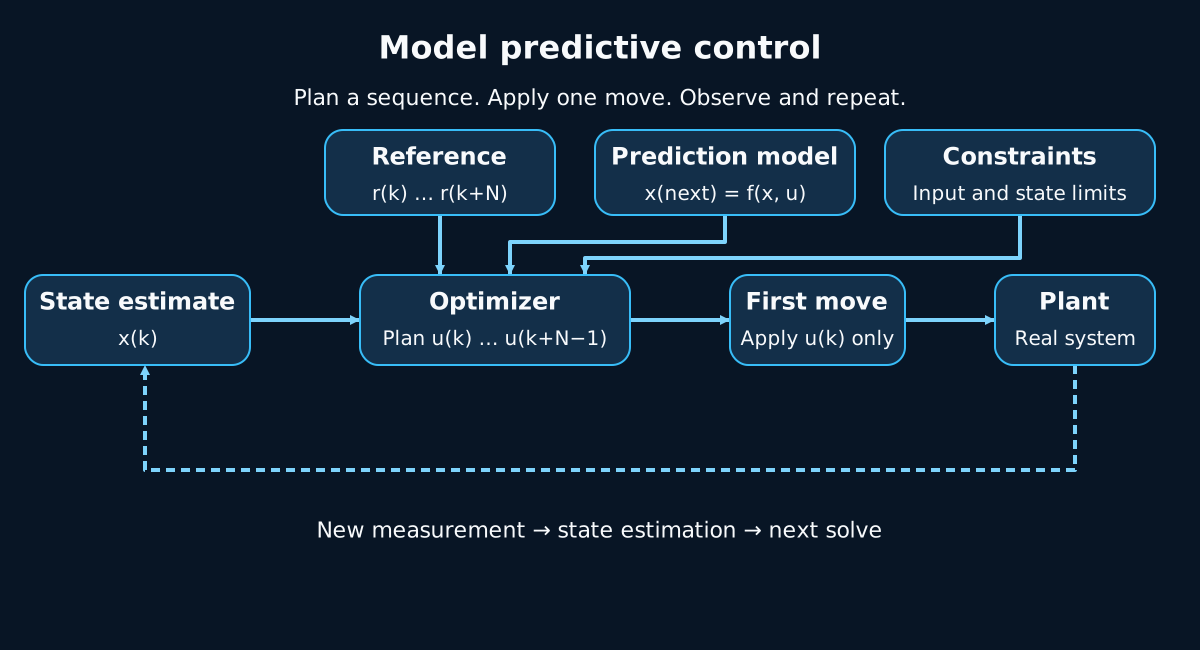 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Model Predictive Control — Acting Within Constraints
Model Predictive Control predicts future behavior with a model, optimizes a constrained input sequence, applies only its first move, and repeats. This primer covers equations, tuning, safety, implementation, and current examples.
Fundamentals · 6 min Control Engineering Primer September 3, 2026Control Engineering Primer: Path Planning — A*, Dijkstra, RRT, RRT*, and PRM
Path planning is not drawing a shortest line. This primer compares grid and continuous-space algorithms while accounting for robot footprint, map uncertainty, computation, SLAM/Nav2 integration, and safety.
Fundamentals · 5 min Control Engineering Primer September 3, 2026Control Engineering Primer: PID Control — Working Across Three Time Scales
PID is not merely three gains. This primer connects its intuition and equations to sampling, saturation, anti-windup, tuning, safety, ROS 2, and real implementation checks.
Fundamentals · 7 min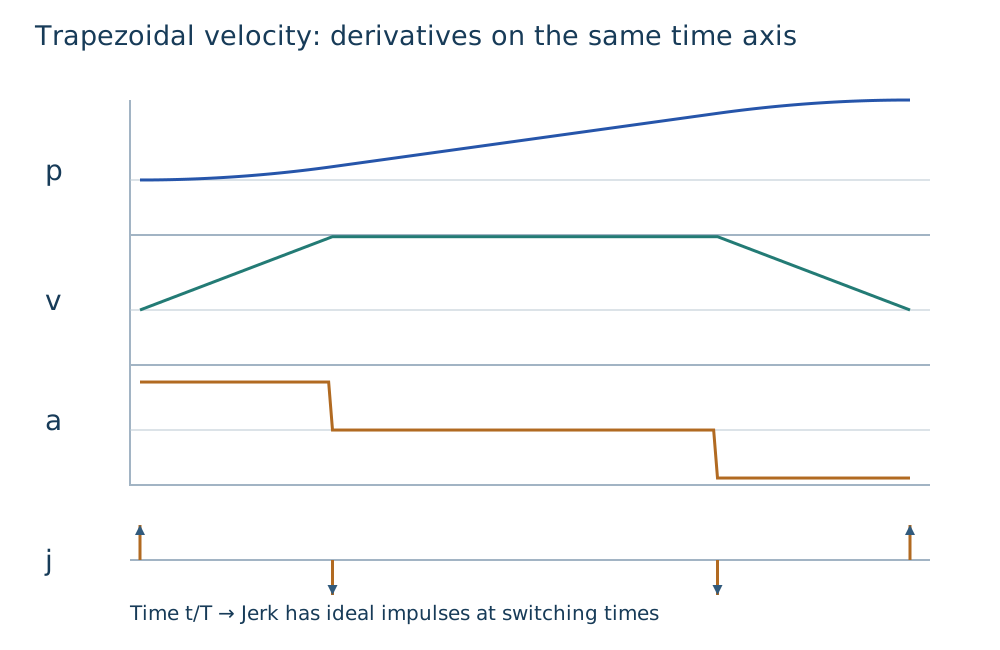 Control Engineering Primer
September 3, 2026
Control Engineering Primer: Trajectory Generation — Minimum Jerk, Quintics, and Trapezoidal Profiles
A path says where to travel; a trajectory says when and with what velocity, acceleration, and jerk. This primer covers minimum-jerk, quintic, trapezoidal profiles, constraints, safety, and ROS 2 integration.
Fundamentals · 4 min