#RANSAC
 Computer Vision Primer
September 7, 2026
Feature Tracking Primer — How to Avoid Losing the Same Point Between Frames
Feature tracking is the process of matching the same physical point across frames in a video sequence. This article organizes template tracking, Lucas–Kanade optical flow, descriptor matching, RANSAC, outlier rejection, and Kalman prediction with equations and implementation steps, and explains the conditions under which Visual Odometry and SLAM break down, along with mitigations.
Fundamentals · 6 min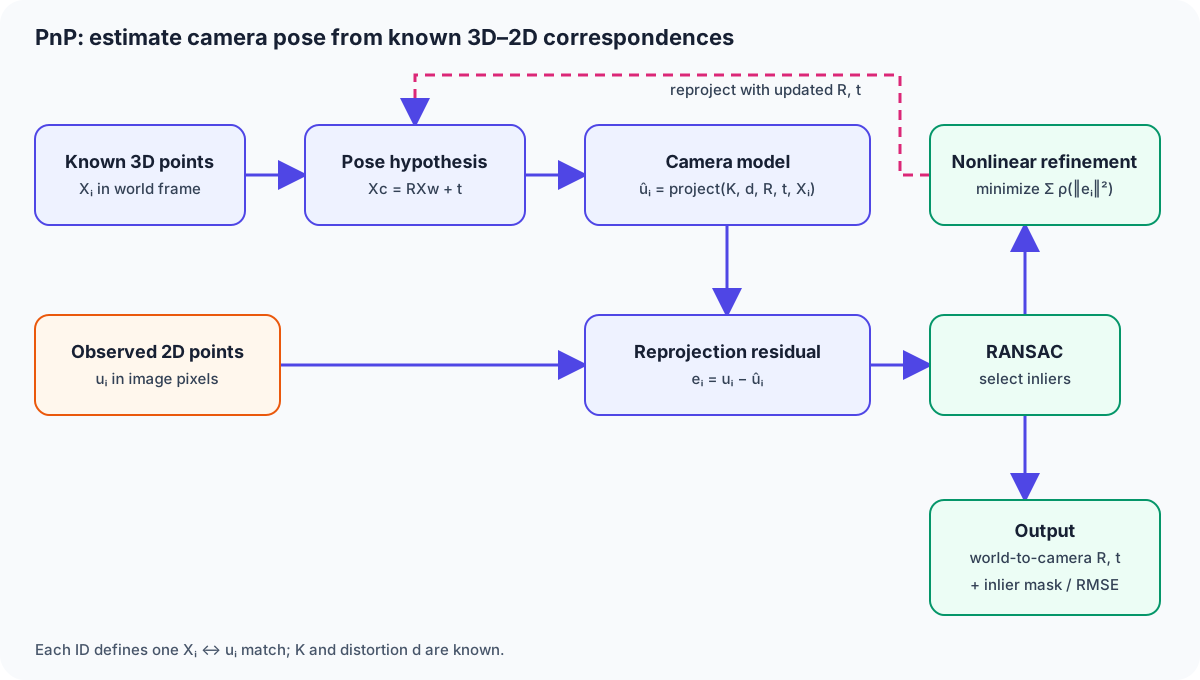 Computer Vision Primer
September 7, 2026
PnP Primer — Recovering Camera Pose from Nothing but 3D Points and an Image
Perspective-n-Point (PnP) is the geometric problem of estimating a camera's position and orientation from known 3D points and their corresponding image points. This article works through the projection equation, P3P/AP3P, EPnP, iterative optimization, RANSAC, planar degeneracy, and how PnP is used in Visual SLAM, AR, and surveying, with the math and an implementation checklist.
Fundamentals · 8 min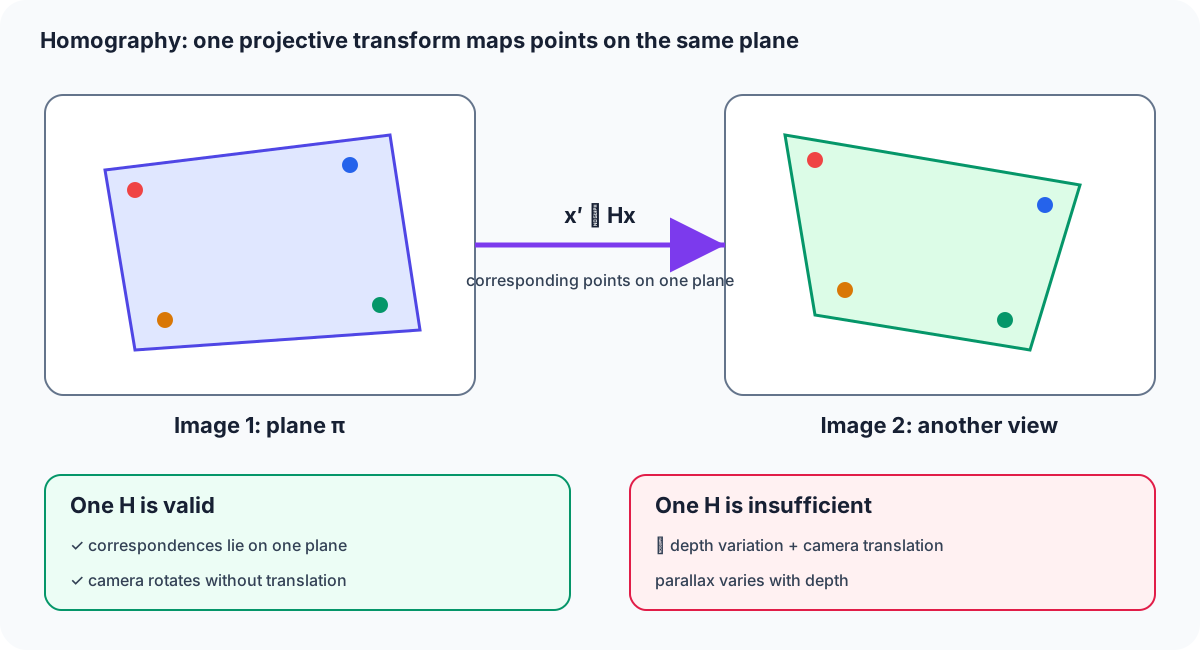 Computer Vision Primer
September 4, 2026
Homography Primer — Describing Planar Correspondence With a Single 3x3 Matrix
A homography is the relation that ties together points on the same plane, or the view of a purely rotating camera, using a single 3x3 projective transform. This article covers DLT-based estimation, robustification with RANSAC, decomposition into rotation, translation, and plane normal, and when to use it versus epipolar geometry, alongside applications like image stitching and AR plane tracking, with equations and diagrams.
Fundamentals · 8 min Computer Vision Primer
September 3, 2026
Epipolar Geometry — Reading Depth and Camera Motion from Two Images
Epipolar geometry is the theory that constrains how the same 3D point projects into two images. This article systematically explains the Fundamental Matrix and Essential Matrix, the 8-point and 5-point algorithms, RANSAC, triangulation, the choice between epipolar geometry and homography, calibration, OpenCV/COLMAP implementation, failure conditions, and recent learning-based estimation, with equations and diagrams.
Fundamentals · 16 min