#3D Reconstruction
 Computer Vision Primer
September 7, 2026
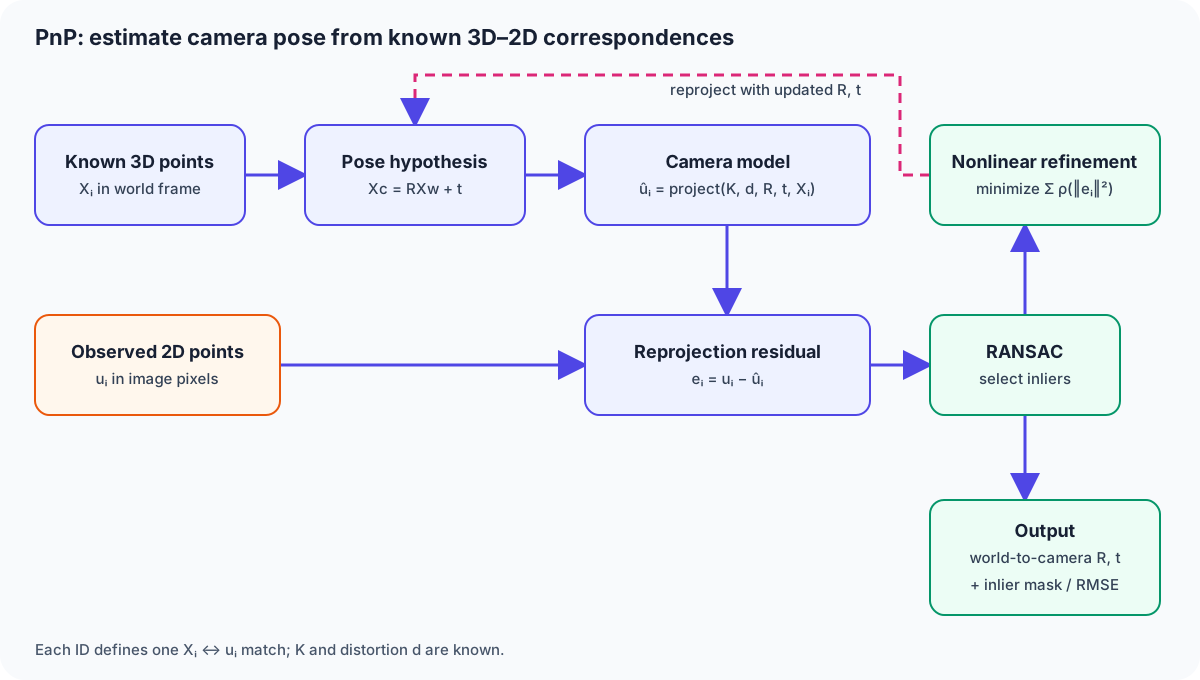
PnP Primer — Recovering Camera Pose from Nothing but 3D Points and an Image
Perspective-n-Point (PnP) is the geometric problem of estimating a camera's position and orientation from known 3D points and their corresponding image points. This article works through the projection equation, P3P/AP3P, EPnP, iterative optimization, RANSAC, planar degeneracy, and how PnP is used in Visual SLAM, AR, and surveying, with the math and an implementation checklist.
Fundamentals · 8 min Computer Vision Primer September 4, 2026Multi-View Stereo Primer — Filling a Sparse Point Cloud Into Dense 3D Shape
Multi-View Stereo (MVS) recovers dense 3D shape from many images using known camera poses. This article systematically covers the core principle of photo-consistency, the two classical approaches of Plane-Sweep and Patch-based (PMVS), deep-learning-based methods epitomized by MVSNet, and meshing via depth-map fusion, alongside the relationship to stereo and depth cameras, with equations and diagrams.
Fundamentals · 11 min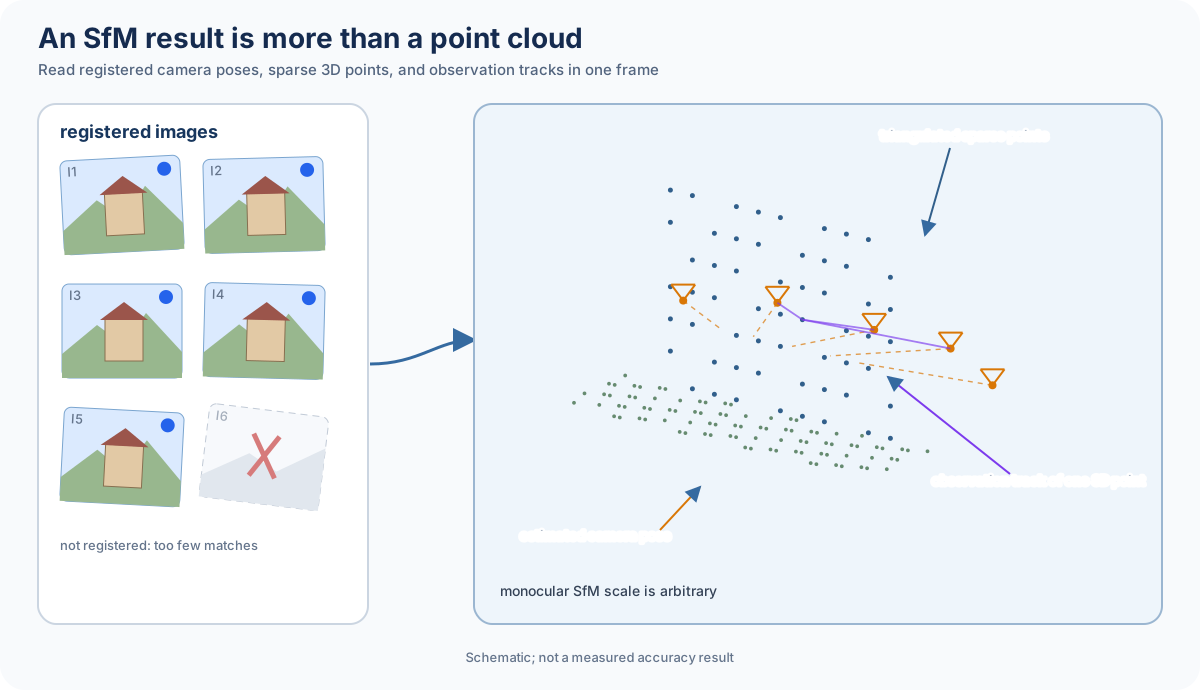 Computer Vision Primer
September 4, 2026
Structure from Motion Primer — Recovering 3D and Camera Positions Together From an Unordered Set of Photos
Structure from Motion (SfM) recovers both a scene's 3D structure and every camera pose simultaneously from a set of photos whose order and shooting positions are unknown. This article systematically covers feature matching, geometric verification, the two reconstruction strategies of Incremental and Global SfM, triangulation, the relationship to Bundle Adjustment, and the difference from Visual-SLAM, alongside current implementations like COLMAP.
Fundamentals · 10 min