#SfM
 Computer Vision Primer
September 4, 2026
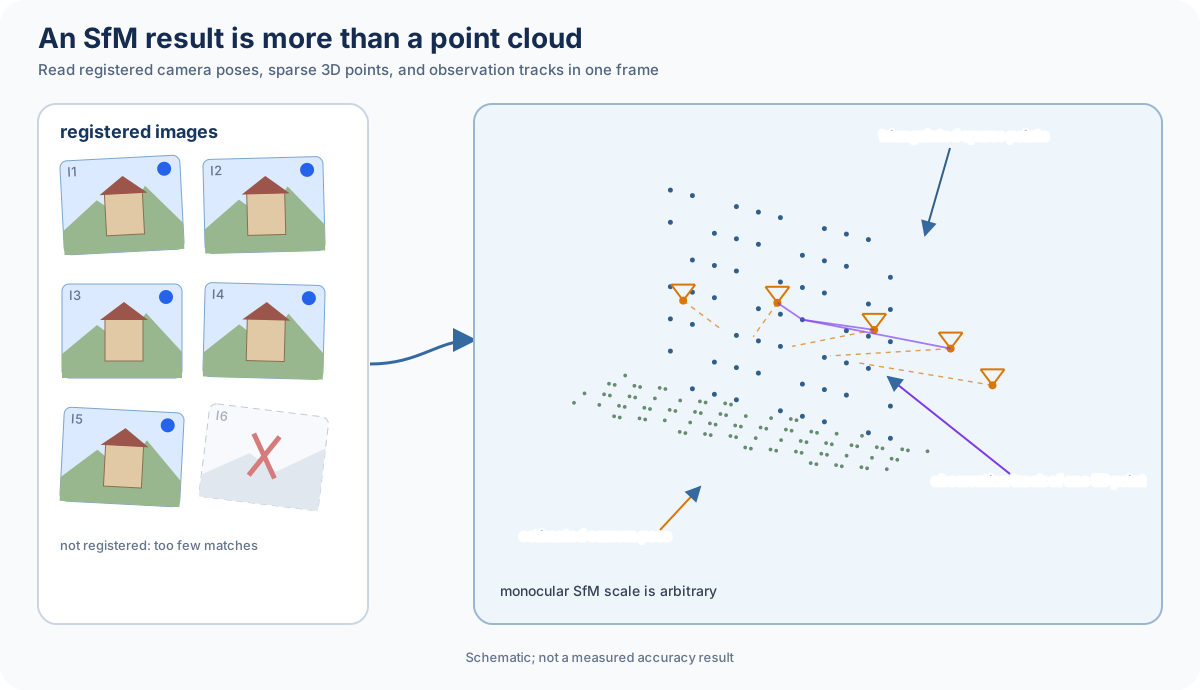
Structure from Motion Primer — Recovering 3D and Camera Positions Together From an Unordered Set of Photos
Structure from Motion (SfM) recovers both a scene's 3D structure and every camera pose simultaneously from a set of photos whose order and shooting positions are unknown. This article systematically covers feature matching, geometric verification, the two reconstruction strategies of Incremental and Global SfM, triangulation, the relationship to Bundle Adjustment, and the difference from Visual-SLAM, alongside current implementations like COLMAP.
Fundamentals · 10 min Computer Vision Primer
September 3, 2026
Epipolar Geometry — Reading Depth and Camera Motion from Two Images
Epipolar geometry is the theory that constrains how the same 3D point projects into two images. This article systematically explains the Fundamental Matrix and Essential Matrix, the 8-point and 5-point algorithms, RANSAC, triangulation, the choice between epipolar geometry and homography, calibration, OpenCV/COLMAP implementation, failure conditions, and recent learning-based estimation, with equations and diagrams.
Fundamentals · 16 min