#Computer Vision
 Computer Vision Primer
September 13, 2026
Monocular Depth Estimation — From Relative Order to Metric Distance
A primer on monocular depth: relative versus metric depth, scale ambiguity, evaluation protocols, and failure conditions.
Learning guide · 3 min Computer Vision Primer
September 13, 2026
Neural 3D — Novel-View Synthesis and Separate Visual/Geometric Evaluation
A primer on neural scene representations, novel-view synthesis, held-out views, and separate visual and geometric evaluation.
Learning guide · 2 min Computer Vision Primer September 4, 2026Camera Calibration Primer — Recovering Lens Distortion and Intrinsic Parameters
Camera calibration is the process of recovering the intrinsic parameters and lens distortion needed to map pixel coordinates onto 3D space. From revisiting the pinhole model, through radial and tangential distortion models, Zhang's planar-pattern method, reprojection-error optimization, to what breaks downstream in Visual SLAM and VO when calibration drifts — a systematic walkthrough with equations and diagrams.
Fundamentals · 9 min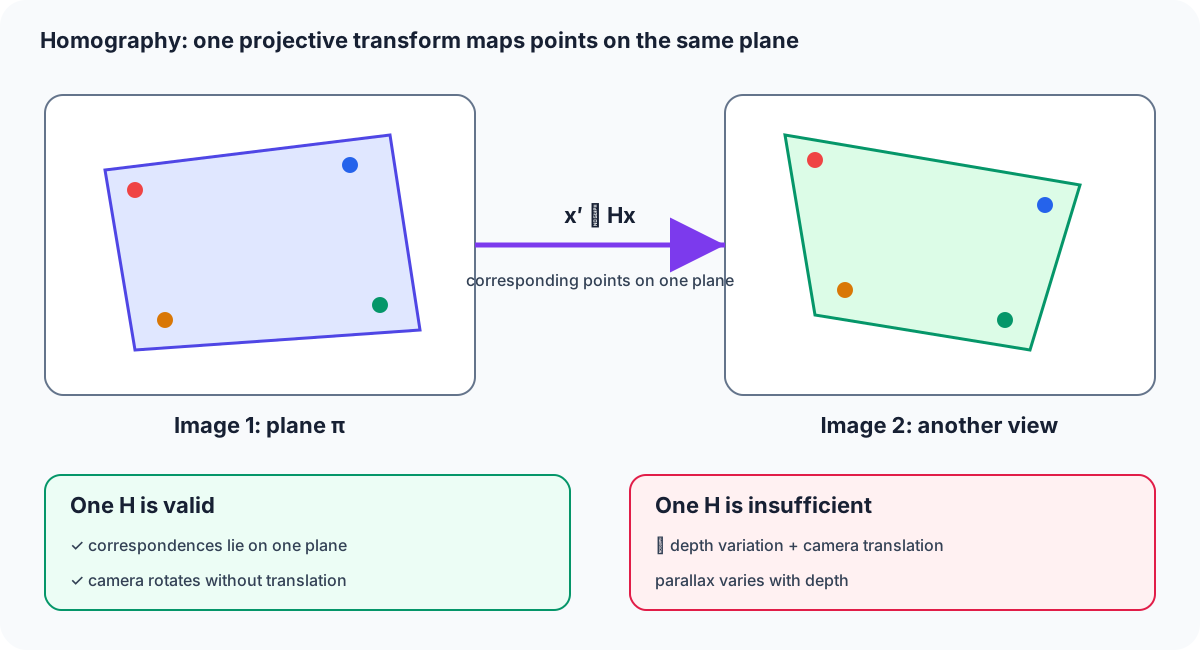 Computer Vision Primer
September 4, 2026
Homography Primer — Describing Planar Correspondence With a Single 3x3 Matrix
A homography is the relation that ties together points on the same plane, or the view of a purely rotating camera, using a single 3x3 projective transform. This article covers DLT-based estimation, robustification with RANSAC, decomposition into rotation, translation, and plane normal, and when to use it versus epipolar geometry, alongside applications like image stitching and AR plane tracking, with equations and diagrams.
Fundamentals · 8 min Computer Vision Primer September 4, 2026Multi-View Stereo Primer — Filling a Sparse Point Cloud Into Dense 3D Shape
Multi-View Stereo (MVS) recovers dense 3D shape from many images using known camera poses. This article systematically covers the core principle of photo-consistency, the two classical approaches of Plane-Sweep and Patch-based (PMVS), deep-learning-based methods epitomized by MVSNet, and meshing via depth-map fusion, alongside the relationship to stereo and depth cameras, with equations and diagrams.
Fundamentals · 11 min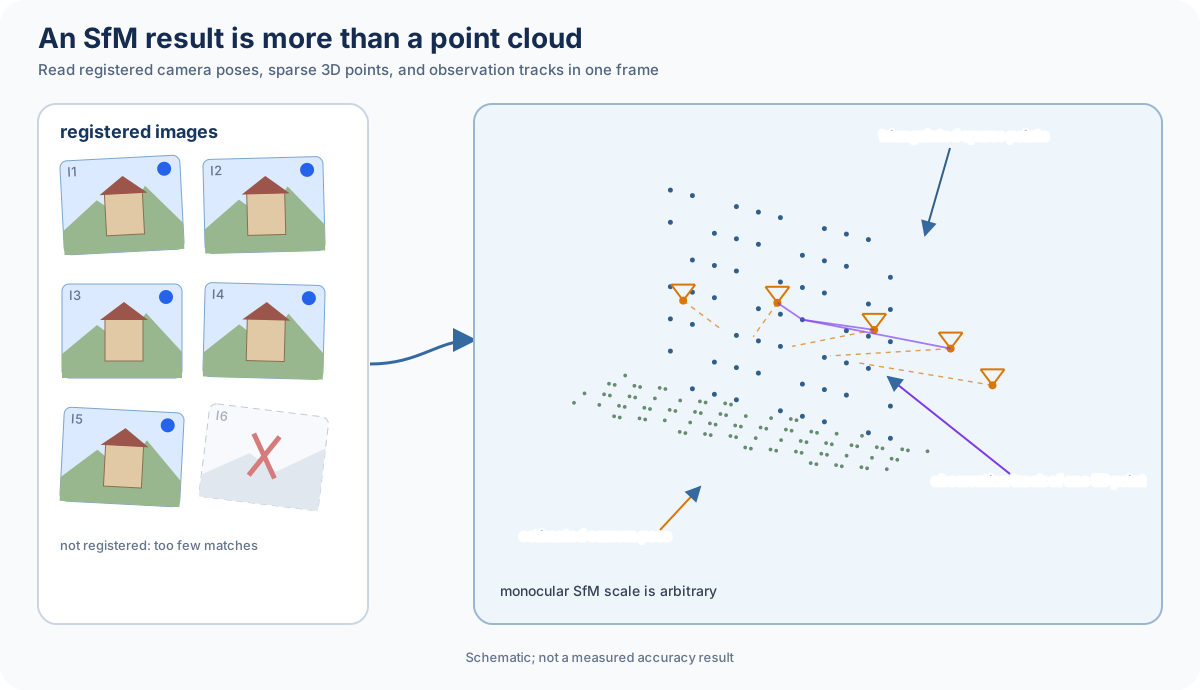 Computer Vision Primer
September 4, 2026
Structure from Motion Primer — Recovering 3D and Camera Positions Together From an Unordered Set of Photos
Structure from Motion (SfM) recovers both a scene's 3D structure and every camera pose simultaneously from a set of photos whose order and shooting positions are unknown. This article systematically covers feature matching, geometric verification, the two reconstruction strategies of Incremental and Global SfM, triangulation, the relationship to Bundle Adjustment, and the difference from Visual-SLAM, alongside current implementations like COLMAP.
Fundamentals · 10 min Machine Learning Primer September 4, 2026Machine Learning Primer: Pose Estimation
Pose estimation infers human or object keypoints and 6D pose from images. This primer covers coordinates, losses, occlusion, evaluation, and safety.
Fundamentals · 4 min Computer Vision Primer
September 3, 2026
Epipolar Geometry — Reading Depth and Camera Motion from Two Images
Epipolar geometry is the theory that constrains how the same 3D point projects into two images. This article systematically explains the Fundamental Matrix and Essential Matrix, the 8-point and 5-point algorithms, RANSAC, triangulation, the choice between epipolar geometry and homography, calibration, OpenCV/COLMAP implementation, failure conditions, and recent learning-based estimation, with equations and diagrams.
Fundamentals · 16 min Computer Vision Primer
September 3, 2026
Feature Detection Primer
Feature detection selects "places you can find again" in an image and uses them for matching. This article connects the principles of corners, blobs, DoG, FAST, ORB, and SIFT with robustness, evaluation, current tools, and learning-based methods into a single coherent picture.
Fundamentals · 13 min