Tag · 3 entries
#Sim-to-Real
Reinforcement Learning Primer
September 3, 2026
 Reinforcement Learning Primer
September 3, 2026
Reinforcement Learning Basics — MDPs, Bellman Equations, and Exploration for Robots
Reinforcement learning is a closed loop in which an agent chooses actions from observations and maximizes delayed rewards. This primer explains MDPs, value functions, policies, Bellman equations, exploration versus exploitation, reward design, and the path from simulation to a real robot.
Fundamentals · 6 min Reinforcement Learning Primer September 3, 2026Model-Based Reinforcement Learning and Sim-to-Real
World models, prediction error, MPC, domain randomization, system identification, and safety monitoring for real machines.
Fundamentals · 4 min
Reinforcement Learning Primer
September 3, 2026
Policy Gradients, PPO, and SAC — Stable Continuous Control for Robots
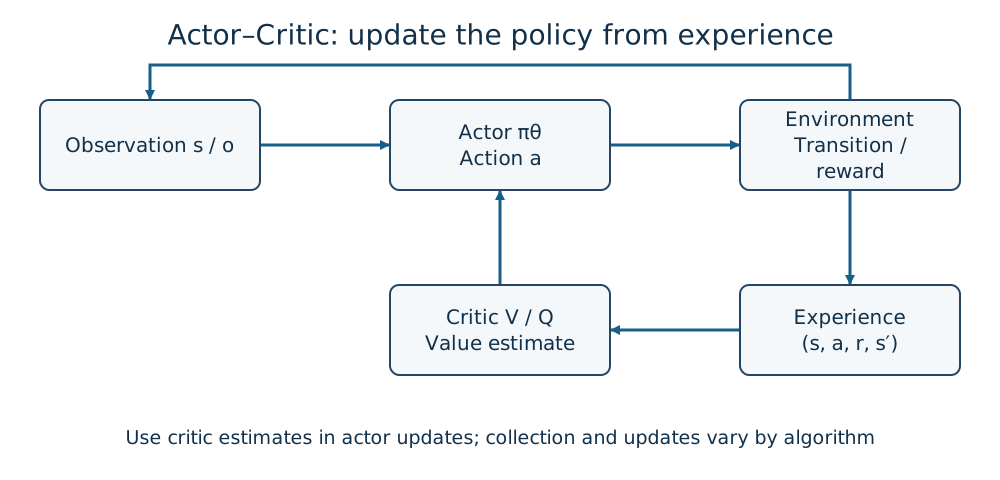
Policy gradients update a policy directly so that steering, thrust, and joint torque can remain continuous. This article connects Actor-Critic, PPO, and SAC, then covers clipping, entropy regularization, evaluation, and the safety boundary for Sim-to-Real transfer.
Fundamentals · 5 min